blockWorkspace2d
2d Workspace

Extends from Modelica.Blocks.Interfaces.MO (Multiple Output continuous control block), Servomechanisms.Utilities.IconXY.
Information
General
With this component the workspace of planar 2 DOF mechanism can be obtain.
Implementation
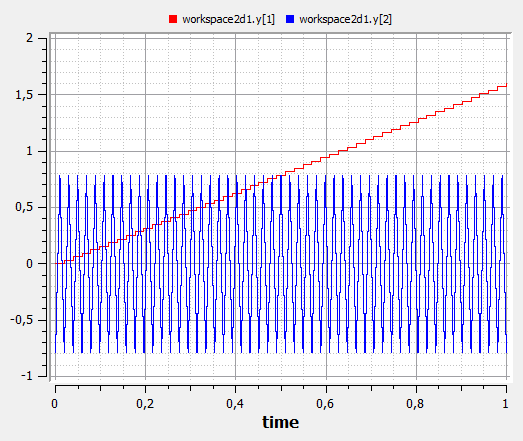
This block generates a sweep between min1 and max1 values according to the step (paso1) for the output y[1]. For each step in y[1] a sweep fordwards and then backwards is generated for y[2] between min2 and max2 with paso2. In this way all the combinations for two variables are included.
Notes
- The user must input the range of both joint variables and use angular or positional sources connected directly to the mechanism connectors. (Modelica.Mechanics.Rotational.Sources.Position or Modelica.Mechanics.Translational.Sources.Position).
- The parameter exact in each position source should be true to reduce the time of simulation.
Example
An example can be found in Servomechanisms.Examples.RRServomechanisms.RRWorkspace.
The outputs using default parameters are:
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Integer | nout (from MO) | 1 | Number of outputs |
| Real | min1 | 0 | min of variable 1 |
| Real | max1 | pi/2 | max of variable 1 |
| Real | min2 | -pi/4 | min of variable 2 |
| Real | max2 | pi/4 | max of variable 2 |
| Real | paso1 | (max1 - min1)/50 | increment of variable 1 |
| Real | paso2 | (max2 - min2)/50 | increment of variable 2 |
| Real | tiempo | ((2*(max2 - min2)/paso2 + 1)*(1 + (max1 - min1)/paso1))^(-1) | for a duration of 1 sec leave the default value |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| RealOutput[nout] | y (from MO) | Connector of Real output signals |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | down |