modelACmachine
AC machine base, 3-phase abc
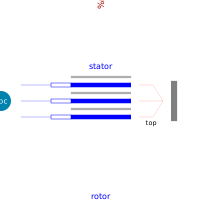
Extends from Ports.YDport_p (AC one port Y or Delta topology 'positive').
Information
Contains the pole-pair transformation
  pp*airgap.phi = phi_el;
  airgap.tau = -pp*tau_el;
between the 'electrical' variables phi_el and tau_el and the 'mechanical' variables airgap.phi and airgap.tau.
The connector 'airgap' transfers the electromagnetic rotor-torque to the mechanical system.
The electric reference frame can specified by the machine rotor. Use this choice ONLY if really necessary and care about restrictions. Choosing
isRef = trueinduces
term.theta = {-phi_el_ini, phi_el}
and therefore
omega = {0, w_el}
not allowing steady-state initialisation for asynchronous machines. Note that
phi_el = pole_pair_number*phi_mechanicalMore info see at 'Machines.Asynchron' and 'Machines.Synchron'.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Integer | pp | 1 | pole-pair number |
| Boolean | stIni_en | true | enable steady-state initial equation |
| SI.Angle | phi_el_ini | 0 | initial rotor angle electric |
| SI.AngularVelocity | w_el_ini | 0 | initial rotor angular velocity el |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Base.Interfaces.ACabc_p | term (from Port_p) | positive terminal | |
| Base.Interfaces.Rotation_n | airgap | electro-mechanical connection | |
| Base.Interfaces.ThermalV_n | heat | heat source port {stator, rotor} |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Topology.Y | top (from YDport_p) | Y or Delta topology | |
| SI.Voltage | v (from YDport_p) | top.v_cond | voltage conductor |
| SI.Current | i (from YDport_p) | top.i_cond | current conductor |
| SI.Voltage | v_n (from YDport_p) | top.v_n | voltage neutral |
| SI.Current | i_n (from YDport_p) | top.i_n | current neutral to ground |
| SI.Angle | phi_el | rotor angle electric (syn: +pi/2) | |
| SI.AngularVelocity | w_el | rotor angular velocity el | |
| SI.Torque | tau_el | electromagnetic torque |
Contents
| Name | Description |
|---|---|
 atan2protected |