modelSynchronBase
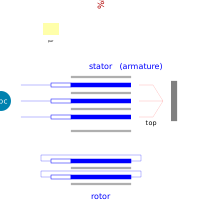
Extends from SynTransform (Synchronous machine base0, 3-phase abc).
Information
General model of synchronous machine.
Stator: one winding each in d-axis, q-axis, o-axis.
Rotor: n_d windings in d-axis (field f, (n_d-1) damper D1, ..), n_q windings in q-axis (damper Q1, ..).
See also equivalent circuit on 'Diagram layer' of
Parameters.Synchron !
  v, i:          stator-voltage and -current abc reference-system
  v_s, i_s:      stator-voltage and -current dqo rotor-system
  v_rd, i_rd:    rotor-voltage and -current d-axis rotor-system
  v_rq, i_rq:    rotor-voltage and -current q-axis rotor-system
The model is valid for reference systems with arbitrary angular orientation theta[2].
Voltage of field-winding:
Machine- and excitation model should use the same value for the (unscaled) field voltage Vf_nom.
This value is calculated from If_nom, defined through V=V_nom at open terminal.
As the machine model is stator-scaled, the default values
  If_nom = I_nom = S_nom/V_nom
  Vf_nom = V_nom
are sufficient when unscaled values for the field-winding are not of interest.
The magnetic flux Psi_pm of the permanent magnet (if present) is defined by
  Psi_pm = psi_pm*Psi_nom
  Psi_nom = V_nom/omega_nom = V_nom/(pp*w_nom)
where psi_pm relates to the induced armature voltage v_op at open-terminal and omega_nom as
psi_pm = v_op/V_nom
The power angle is calculated if so desired. Note that for an inverter driven machine the power angle signal is oscillating with the source voltage.
  powerAngle:   difference (angle of rotor) - (angle of terminal_voltage)
                (> 0: generator, < 0: motor)
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Integer | pp (from ACmachine) | 1 | pole-pair number |
| Boolean | stIni_en (from ACmachine) | true | enable steady-state initial equation |
| SI.Angle | phi_el_ini (from ACmachine) | 0 | initial rotor angle electric |
| SI.AngularVelocity | w_el_ini (from ACmachine) | 0 | initial rotor angular velocity el |
| Parameters.Synchron | par | machine parameter |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Base.Interfaces.ACabc_p | term (from Port_p) | positive terminal | |
| Base.Interfaces.Rotation_n | airgap (from ACmachine) | electro-mechanical connection | |
| Base.Interfaces.ThermalV_n | heat (from ACmachine) | heat source port {stator, rotor} |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Topology.Y | top (from YDport_p) | Y or Delta topology | |
| SI.Voltage | v (from YDport_p) | top.v_cond | voltage conductor |
| SI.Current | i (from YDport_p) | top.i_cond | current conductor |
| SI.Voltage | v_n (from YDport_p) | top.v_n | voltage neutral |
| SI.Current | i_n (from YDport_p) | top.i_n | current neutral to ground |
| SI.Angle | phi_el (from ACmachine) | rotor angle electric (syn: +pi/2) | |
| SI.AngularVelocity | w_el (from ACmachine) | rotor angular velocity el | |
| SI.Torque | tau_el (from ACmachine) | electromagnetic torque |