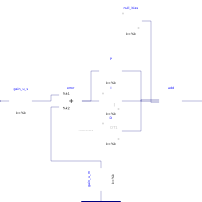
modelPID_Control2
Proportional controller: y = yb + Kc*e
Extends from Modelica.Blocks.Interfaces.SVcontrol (Single-Variable continuous controller).
Parameters
| Type | Name | Default | Description |
|---|
| Boolean | directActing | true | =false reverse acting |
| Real | k | 1 | Error gain |
| Real | yb | 0 | Output bias |
| Real | k_s | 1 | Scaling factor for setpoint: set = k_s*u_s |
| Real | k_m | 1 | Scaling factor for measurment: meas = k_m*u_m |
| SI.Time | Ti | 1 | Time Constant (Ti>0 required) |
| SI.Time | Td | 0.1 | Time Constant of Derivative block |
| Boolean | derMeas | true | =true for derivative on measured value to avoid kick else error |
| Real | Nd | 10 | The higher Nd, the more ideal the derivative block |
| SI.Time | unitTime | 1 | |
| Real | Kc | k*(if directActing then +1 else -1) | |
| Initialization |
| Modelica.Blocks.Types.Init | initType | Modelica.Blocks.Types.Init.NoInit | Type of initialization (1: no init, 2: steady state, 3: initial state, 4: initial output) |
| Real | xi_start | 0 | Initial or guess value of integral state |
| Real | xd_start | 0 | Initial or guess value of derivative state |
| Real | y_start | 0 | Initial value of output |