modelP_Control2
Proportional controller: y = yb + Kc*e
Extends from Modelica.Blocks.Interfaces.SVcontrol (Single-Variable continuous controller).
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | directActing | true | =false reverse acting |
| Real | k | 1 | Error gain |
| Real | yb | 0 | Output bias |
| Real | k_s | 1 | Scaling factor for setpoint: set = k_s*u_s |
| Real | k_m | 1 | Scaling factor for measurment: meas = k_m*u_m |
| Real | Kc | k*(if directActing then +1 else -1) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| RealInput | u_s (from SVcontrol) | Connector of setpoint input signal | |
| RealInput | u_m (from SVcontrol) | Connector of measurement input signal | |
| RealOutput | y (from SVcontrol) | Connector of actuator output signal |
Components
| Type | Name | Default | Description |
|---|---|---|---|
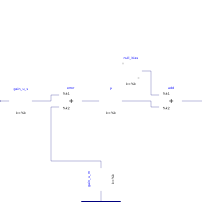
| Modelica.Blocks.Math.Gain | P | Proportional part of PID controller | |
| Modelica.Blocks.Math.Gain | gain_u_s | ||
| Modelica.Blocks.Math.Gain | gain_u_m | ||
| Modelica.Blocks.Math.Add | add | ||
| Modelica.Blocks.Sources.Constant | null_bias | ||
| Modelica.Blocks.Math.Add | error |