modelBatteryElectricVehicle
Extends from TransiEnt.Basics.Icons.Model (Icon for models).
Information
1. Purpose of model
This model calculates the empiric electrical behavior of an electric vehicle in combination with non-public charging infrastructure (wallbox in low voltage grids) in combination with stochastic driving profiles.
2. Level of detail, physical effects considered, and physical insight
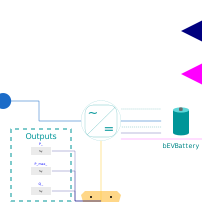
Model is build upon an Onboard Charger model and an Battery model. Please have a look at the Onboard Charger and the Battery documentation
3. Limits of validity
Only valid for low voltage AC grid integration. No DC or high charging power is implemented.
4. Interfaces
Input:
isConnected for the electric connection dependent on the stochastic drivign profile.
controlBus for P_limit, SignalActive and P_input which are further connected to the Onboard Charger.
Output:
epp for connection to a complex root mean square grid simulation
5. Nomenclature
See parameter and variable descriptions in the code.
6. Governing Equations
The equations 6.3 - 6.6 are calculated first before 6.1 and 6.2 are calculated due to the sequential structure of the model.
6.1. State of Charge Alteration
when isConnected then
reinit(bEVBattery.E, max(bEVBattery.SOC - SOC_consumption, 0)* Capacity);
end when;
7. Remarks for Usage
Choose the type of empirical charger data but altering the parameter Charger_params. This changes the Onboard Charger Efficiency and Reactive Power Profile.
8. Validation
The model has been validated against the measurement data which were the bases for the empirical approach. Additionally a comparison with literature information about efficiency and reactive power was performed. The quality of the efficiency measurements was confirmed. After revalidating the data, the reactive power still differed from the data in the literature source. [1]
9. References
[1] K. Sevdari, L. Calearo, B. H. Bakken, P. B. Andersen, und M. Marinelli, “Experimental Validation of Onboard Electric Vehicle Chargers to Improve the Efficiency of Smart Charging Operation,” Sustainable Energy Technologies and Assessments, Bd. 60, S. 103512, Dec. 2023.
10. Version History
ElectricVehicle by Tom Steffen, Techische Universität Hamburg, Institut für Elektrische Energietechnik, 2025
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| TransiEnt.Consumer.Electrical.ElectricVehicle.Characteristics.Renault_Zoe_R110 | Charger_Params | TransiEnt.Consumer.Electrical.ElectricVehicle.Characteristics.Renault_Zoe_R110() | |
| Battery | |||
| Modelica.Units.SI.Power | P_nominal | 11000 | Nominal charge and discharge power |
| Modelica.Units.SI.Voltage | V_nominal | 400 | Nominal voltage |
| Modelica.Units.SI.Energy | Capacity | 90e3*3600 | Battery capacity in Joule |
| Real | SOC_initial | 0.5 | Battery Charge at start |
| Real | SOC_th | 0.95 | If SOC > SOC_th reduce power linearly |
| Real | SOC_stop | 1 | If SOC > SOC_stop stop charging |
| Real | lambda_Pmin | 0.02 | Minimum relative power at SOC limits (0 or 1) |
| Control | |||
| Real | t_deadTime | 2 | Battery reaction dead time on set value |
| Real | tau_dynamics | 3 | Battery dynamic reaction on set value |
| External Control | |||
| ControlType | controlType | TransiEnt.Basics.Types.ControlType.Internal | Type of control (see enumeration) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| TransiEnt.Basics.Interfaces.Electrical.ComplexPowerPort | epp | ||
| TransiEnt.Basics.Interfaces.General.ControlBus | controlBus | ||
| Modelica.Blocks.Interfaces.RealInput | SOC_consumption | ||
| Modelica.Blocks.Interfaces.BooleanInput | isConnected | Boolean Input considering wether the EV is connected to the grid when not driving |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| BEVOnboardCharger | bEVOnboardCharger | ||
| TransiEnt.Storage.Electrical.BEVBattery | bEVBattery | ||
| Modelica.Blocks.Sources.RealExpression | P_ | ||
| Modelica.Blocks.Sources.RealExpression | P_max_ | ||
| Modelica.Blocks.Sources.RealExpression | Q_ |