modelTestTrailerDCPM
Test trailer with DCPM-drive
Extends from Modelica.Icons.Example (Icon for runnable examples).
Information
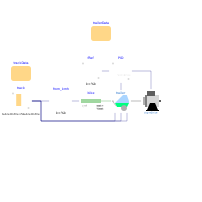
The time table track prescribes:
- the velocity [km/h] of the
bike. - the wind speed [m/s] (positive = in direction of movement / from behind)
- rolling resistance coefficient
- the inclination =
tan(angle)(positive = uphill).
The bike is modeled as a prescribed speed, i.e. the biker is strong enough to reach the prescribed speed. The force between bike and trailer is intended to get compensated by controlling the electrical drive(s) with prescribed torque.
The reference force fRef describes the force demanded from the bike, normally zero.
Negative means additional resistance, positive means additional support for the bike.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| DataRecords.TrailerData | trailerData | ||
| DataRecords.TrackData | trackData |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Components.Trailer | trailer | ||
| Modelica.Blocks.Continuous.LimPID | PID | ||
| Modelica.Blocks.Sources.Constant | fRef | ||
| Modelica.Blocks.Math.Gain | from_kmh | ||
| Modelica.Mechanics.Translational.Sources.Speed | bike | ||
| Components.DcpmDrive | dcpmDrive | ||
| Modelica.Blocks.Sources.CombiTimeTable | track |