modelSpeedCommand
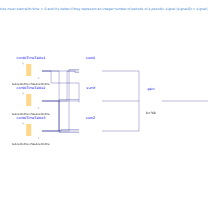
The outputs are three speed reference signals defined through interpolation of table's elements
Extends from DeltaRobot.Icons.SpeedCommand (Icon for 'SpeedCommand' model).
Parameters
| Type | Name | Default | Description |
|---|
| Integer | n | 1 | The reference speeds are repeted 'n' times |
| SI.Time | startTime | 0 | speedRef = 0, for time<startTime |
| SI.Time | deltaTime | 0 | Time between two repetitions of the reference speeds |
| Real | k | 1000*7.11/1500 | Gain |
| String | tableName | "Speeds" | |
| String | fileName | Modelica.Utilities.Files.loadResource("modelica://DeltaRobot/DataTables/SpeedCommand.txt") | |