modelDCMotor_DCPM
DC motor using DC machine from MSL
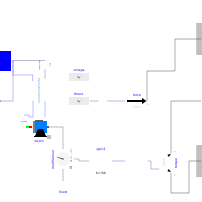
Extends from DroneLibrary.Mechanical.Motor.Templates.DCMotor_Power (DC motor using DC machine from MSL).
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Real | k (from DCMotor_Power) | -1 | Propeller gain. Set to 1 for clockwise, -1 for counterclockwise |
| Modelica.Units.SI.Voltage | VaNominal (from DCMotor_Power) | 5 | Nominal armature voltage for motor |
| Modelica.Units.SI.Current | IaNominal (from DCMotor_Power) | 0.1 | Nominal armature current (>0..Motor, <0..Generator) for motor |
| Modelica.Units.SI.Voltage | V (from DCMotor_Power) | Battery voltage | |
| Modelica.Units.SI.Resistance | R (from DCMotor_Power) | 100 | Resistance at temperature T_ref |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Electrical.Analog.Interfaces.PositivePin | p1 (from DCMotor_Power) | pin to be measured | |
| Modelica.Blocks.Interfaces.RealInput | position (from DCMotor_Power) | Connector of Real input signal | |
| Modelica.Mechanics.MultiBody.Interfaces.Frame_b | torque_1 (from DCMotor_Power) | Coordinate system b fixed to the component with one cut-force and cut-torque | |
| Modelica.Mechanics.MultiBody.Interfaces.Frame_a | torque_2 (from DCMotor_Power) | Coordinate system a fixed to the component with one cut-force and cut-torque | |
| Modelica.Mechanics.MultiBody.Interfaces.Frame_a | force_out (from DCMotor_Power) |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Nonlinear.Limiter | limiter | ||
| Modelica.Electrical.Machines.BasicMachines.DCMachines.DC_PermanentMagnet | dcpm | ||
| Modelica.Electrical.Analog.Basic.Ground | ground | ||
| Electrical.Sources.PowerControl | powerControl | ||
| Modelica.Mechanics.Rotational.Sensors.MultiSensor | multiSensor | ||
| Modelica.Mechanics.MultiBody.Forces.WorldForce | force | ||
| Blocks.Routing.RealExtend | realExtend1 | ||
| Modelica.Blocks.Math.Gain | gain1 | ||
| Blocks.Routing.RealExtend | realExtend | ||
| Modelica.Mechanics.MultiBody.Forces.Torque | torque | ||
| Modelica.Mechanics.Rotational.Components.Fixed | fixed | ||
| Modelica.Blocks.Sources.RealExpression | thrust | ||
| Modelica.Blocks.Sources.RealExpression | omega |