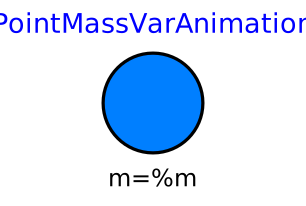
modelPointMassVarAnimation
Rigid body where body rotation and inertia tensor is neglected (6 potential states)
Information
<!DOCTYPE html><HTML><p>This rigid body is a modification of <a href="Modelica.Mechanics.MultiBody.Parts.PointMass.html">Modelica.Mechanics.MultiBody.Parts.PointMass</a>. The animation can be disabled via the boolean input. Therefore, the diameter of the sphere is set to 0.
</p></HTML>
Parameters
| Type | Name | Default | Description |
|---|
| Boolean | animation | true | = true, if animation shall be enabled (show sphere) |
| SI.Mass | m | | Mass of mass point |
| Advanced |
| StateSelect | stateSelect | StateSelect.avoid | Priority to use frame_a.r_0, v_0 (= der(frame_a.r_0)) as states |
Components
| Type | Name | Default | Description |
|---|
| SI.Diameter | sphereDiameter | world.defaultBodyDiameter | Diameter of sphere |
| Types.Color | sphereColor | Modelica.Mechanics.MultiBody.Types.Defaults.BodyColor | Color of sphere |
| Types.SpecularCoefficient | specularCoefficient | world.defaultSpecularCoefficient | Reflection of ambient light (= 0: light is completely absorbed) |
| SI.Position[3] | r_0 | | Position vector from origin of world frame to origin of frame_a, resolved in world frame |
| SI.Velocity[3] | v_0 | | Absolute velocity of frame_a, resolved in world frame (= der(r_0)) |
| SI.Acceleration[3] | a_0 | | Absolute acceleration of frame_a resolved in world frame (= der(v_0)) |