modelLeadLAG
Lead lag process with tracking mode (and limiter)
Extends from IndustrialControlSystems.Controllers.Interfaces.Block (Partial interface for a continuous time control block).
Information
Description
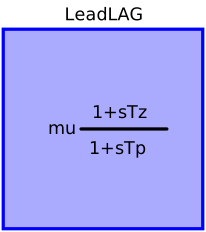
Lead lag continuous time control block.
   Y(s)        (1 + s*Tz)
   ----  = mu ------------
   U(s)        (1 + s*Tp)
AntiWindUp mode
If the boolean flag AntiWindup is tue the output of the block ( y ) saturates at the levels specified by Ymin and Ymax.Tracking mode
If the boolean flag useTS, the inputs TS and TR are enabled.When enabled, is the TS signal is true the output y is forced to follow the track reference signal TR.
While the tracking mode is enabled (TS = true), the state variable follows the Track Reference signal (TR).
In such a way bumpless transitions are guaranteed.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | useTS (from Block) | false | =true, if TS input is enabled |
| Real | mu | 1 | Gain of the system |
| Real | Tp | 1 | Pole time constant |
| Real | Tz | 2 | Zero time constant |
| Real | y_start | 0 | output initial value |
| Tracking | |||
| Real | eps (from Block) | 0.001 | Small time constant used in tracking mode |
| Saturation | |||
| Boolean | AntiWindup (from Block) | false | Flag that enables the antiwindup feature |
| Real | Ymin (from Block) | 0 | Minimum value of Y |
| Real | Ymax (from Block) | 1 | Maximum value of Y |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Interfaces.RealInput | TR (from Block) | Track Reference signal | |
| Modelica.Blocks.Interfaces.BooleanInput | TS (from Block) | Track Switch signal | |
| Modelica.Blocks.Interfaces.RealInput | u (from Block) | input | |
| Modelica.Blocks.Interfaces.RealOutput | y (from Block) | output |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Real | tr (from Block) | track reference value | |
| Boolean | ts (from Block) | track reference signal |
Revisions
- Industrial Control Systems (v 1.0.0) : April-May 2012
- List of revisions:
- 11 May 2012 (author: Marco Bonvini)
- Main Authors:
- Marco Bonvini; <bonvini@elet.polimi.it>
- Alberto Leva <leva@elet.polimi.it>
- Politecnico di Milano
- Dipartimento di Elettronica e Informazione
- Via Ponzio 34/5
- 20133 Milano - ITALIA -
- Copyright:
- Copyright © 2010-2012, Marco Bonvini and Alberto Leva.
- The IndustrialControlSystems package is free software; it can be redistributed and/or modified under the terms of the Modelica license.