modelTestPID_TDOe
Test of the 2DoF digital PID controller with event based Time Division Output (TDO)
Extends from Modelica.Icons.Example (Icon for runnable examples).
Information
Description
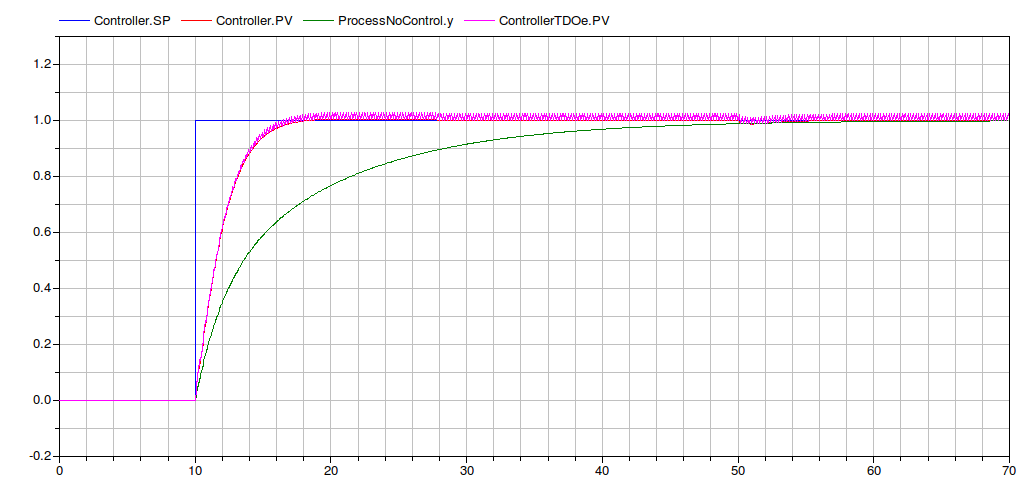
In this example have been compared the 2DoF incremental PID, with its Time Division Output implementation.
The PIDs have to control the process with transfer function
   Y(s)             5*s +1
   ----  =  -----------------------
   U(s)        20*s^2 + 12*s + 1
The image compares the outputs of the process y with and without the controllers action.
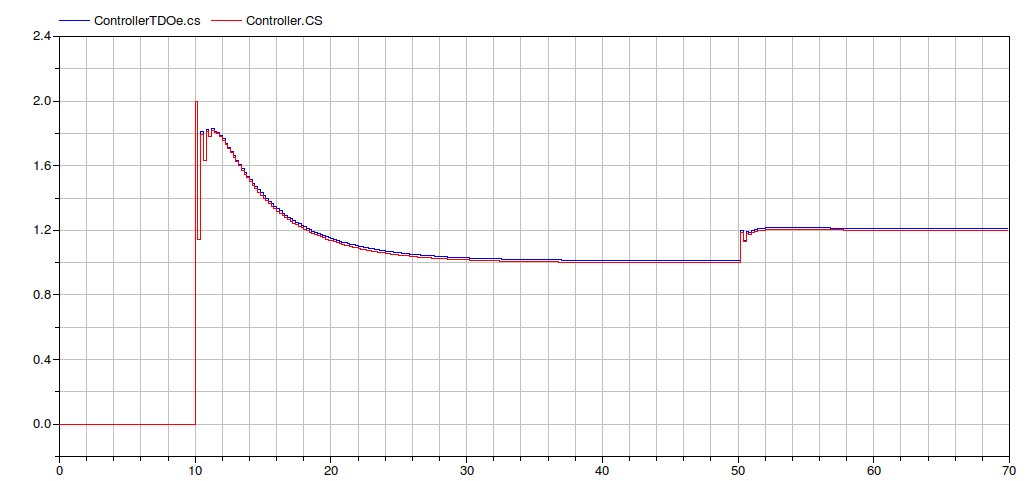
The following image compares the CS computed by the TDO controller (before its conversion), and the CS comuted by the
controller without TDO.
Event Based implementation
The event based implementation of the digital incremental PID with TDO, reduces the time spent for simulating the model. Here follows the simulation results for the considere examples
  Integration started at T = 0 using integration method DASSL
  (DAE multi-step solver (dassl/dasslrt of Petzold modified by Dynasim))
  Integration terminated successfully at T = 70
     CPU-time for integration      : 0.12 seconds
     CPU-time for one GRID interval: 0.24 milli-seconds
     Number of result points       : 1748
     Number of GRID   points       : 501
     Number of (successful) steps  : 7200
     Number of F-evaluations       : 26592
     Number of Jacobian-evaluations: 6373
     Number of (model) time events : 649
     Number of (U) time events     : 0
     Number of state    events     : 0
     Number of step     events     : 0
     Minimum integration stepsize  : 2.09e-06
     Maximum integration stepsize  : 0.0993
     Maximum integration order     : 2
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Sources.Step | step | ||
| PID_2dof_TDO_FullyEventBased | ControllerTDOe | ||
| LinearSystems.Continuous.TransferFunction | ProcessTDOe | ||
| Modelica.Blocks.Math.Feedback | sub | ||
| Modelica.Blocks.Sources.Step | disturb | ||
| PID_2dof | Controller | ||
| LinearSystems.Continuous.TransferFunction | Process | ||
| LinearSystems.Continuous.TransferFunction | ProcessNoControl | ||
| Modelica.Blocks.Math.Feedback | sub1 |
Revisions
- Industrial Control Systems (v 1.0.0) : April-May 2012
- List of revisions:
- 11 May 2012 (author: Marco Bonvini)
- Main Authors:
- Marco Bonvini; <bonvini@elet.polimi.it>
- Alberto Leva <leva@elet.polimi.it>
- Politecnico di Milano
- Dipartimento di Elettronica e Informazione
- Via Ponzio 34/5
- 20133 Milano - ITALIA -
- Copyright:
- Copyright © 2010-2012, Marco Bonvini and Alberto Leva.
- The IndustrialControlSystems package is free software; it can be redistributed and/or modified under the terms of the Modelica license.