modelTestI_bias
Test of the Integral controller with bias
Extends from Modelica.Icons.Example (Icon for runnable examples).
Information
Description
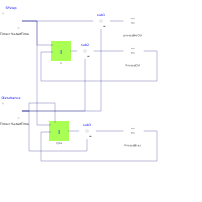
In this example have been tested the Integral controller.
The process to be controlled has the following transfer function
   Y(s)          (1+15s)
   ----  =  ----------------
   U(s)       (1+10s)(1+2s)
There are three processes:
- without controller,
- with a I controller,
- and a I controller with bias signal
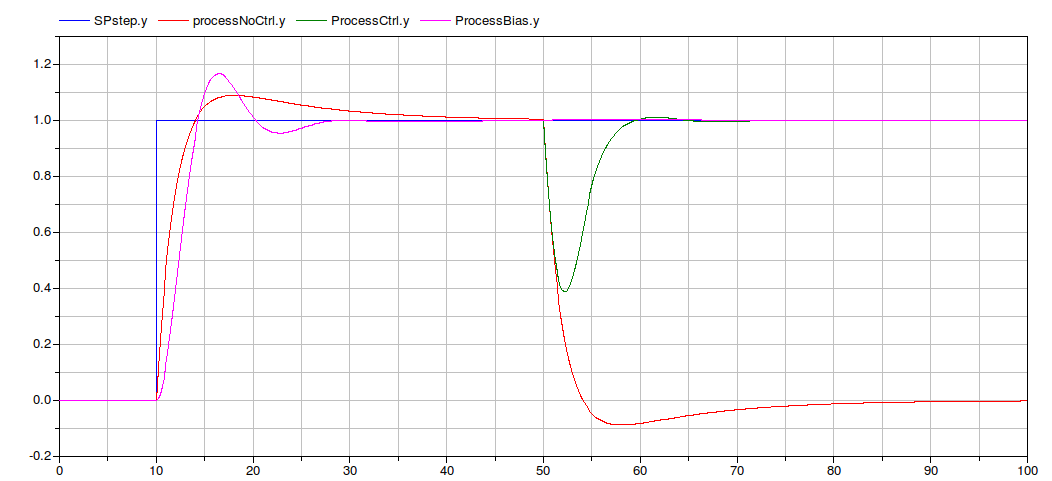
The output signal of the process without control is the red line. Of course the system performs poorly, in particular when an external disturb is applied.
In the closed loop system, the integral controller reach the SP with a null steady state error. The disturbance can be rejected using the bias signal of the controller (pink line).
Discrete time
If the model parameter Ts is >=0 the continuous time controllers are replaced by their discrete time versions.The effect of various discretisation method can be studied.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Sampling time | |||
| Real | Ts | 0 | if Ts>=0 then discrete time controller, otherwise continuous time |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Sources.Step | SPstep | ||
| I | R | ||
| Modelica.Blocks.Math.Feedback | sub2 | ||
| I | R_Bias | ||
| Modelica.Blocks.Math.Feedback | sub3 | ||
| Modelica.Blocks.Sources.Step | Disturbance | ||
| LinearSystems.Continuous.TransferFunction | ProcessCtrl | ||
| LinearSystems.Continuous.TransferFunction | processNoCtrl | ||
| LinearSystems.Continuous.TransferFunction | ProcessBias | ||
| Modelica.Blocks.Math.Feedback | sub1 |
Revisions
- Industrial Control Systems (v 1.0.0) : April-May 2012
- List of revisions:
- 11 May 2012 (author: Marco Bonvini)
- Main Authors:
- Marco Bonvini; <bonvini@elet.polimi.it>
- Alberto Leva <leva@elet.polimi.it>
- Politecnico di Milano
- Dipartimento di Elettronica e Informazione
- Via Ponzio 34/5
- 20133 Milano - ITALIA -
- Copyright:
- Copyright © 2010-2012, Marco Bonvini and Alberto Leva.
- The IndustrialControlSystems package is free software; it can be redistributed and/or modified under the terms of the Modelica license.