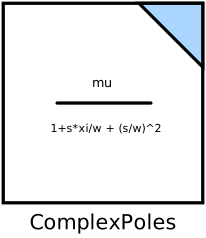
modelComplexPoles
Process with complex poles
Extends from Interfaces.DiscreteBaseBlock (Partial discrete time block interfaces).
Information
Description
Discretised version of the continuous time transfer function of a process with complex poles.
   Y(s)                      1
   ----  = mu ------------------------------------
   U(s)        (1 + s*2*xi/omegan + (s/omegan)^2)
The damping coefficient xi must be between [0,1].
Discretisation
The discretisation of the continuos time transfer function has been performed with the bilinear transformation formula
                 z - 1
  s = ------------------------------
        z*alpha*Ts - (alpha - 1)*Ts
that is equivalent to- Forward Euler (FE) if
alpha = 0
- Backward Euler (BE) if
alpha = 1
- Tustin (TU) if
alpha = 0.5
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Discretisation | |||
| Real | Ts (from DiscreteBaseBlock) | 0.01 | Sampling time [s] |
| IndustrialControlSystems.LinearSystems.Discrete.Types.discrMethod | method (from DiscreteBaseBlock) | IndustrialControlSystems.LinearSystems.Discrete.Types.discrMethod.BE | Discretisation method |
| Block parameters | |||
| Real | xi | 0.8 | Damping coefficient |
| Real | omegan | 0.1 | Natural frequency |
| Real | mu | 1 | Gain |
| Initial conditions | |||
| Real | y_start | 0 | Output initial value |
| Real | dy_start | 0 | Slope initial value |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Interfaces.RealInput | u (from BaseBlock) | input | |
| Modelica.Blocks.Interfaces.RealOutput | y (from BaseBlock) | output |
Revisions
- Industrial Control Systems (v 1.0.0) : April-May 2012
- List of revisions:
- 11 May 2012 (author: Marco Bonvini)
- Main Authors:
- Marco Bonvini; <bonvini@elet.polimi.it>
- Alberto Leva <leva@elet.polimi.it>
- Politecnico di Milano
- Dipartimento di Elettronica e Informazione
- Via Ponzio 34/5
- 20133 Milano - ITALIA -
- Copyright:
- Copyright © 2010-2012, Marco Bonvini and Alberto Leva.
- The IndustrialControlSystems package is free software; it can be redistributed and/or modified under the terms of the Modelica license.