modelLineForceWithTwoMasses
Extends from Interfaces.LineForceBase (Base model for line force elements).
Information
This component is used to exert a line force between the origin of frame_a and the origin of frame_b by attaching components of the 1-dimensional translational mechanical library of Modelica (Modelica.Mechanics.Translational) between the two flange connectors flange_a and flange_b. Optionally, there are two point masses on the line connecting the origin of frame_a and the origin of frame_b. These point masses approximate the masses of the force element. The locations of the two point masses are defined by their (fixed) distances of L_a relative to frame_a and of L_b relative to frame_b, respectively.
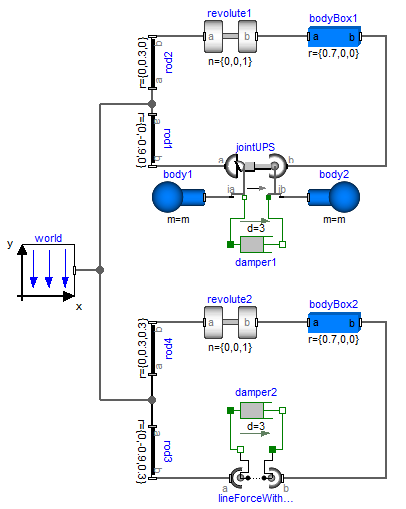
In example MultiBody.Examples.Elementary.LineForceWithTwoMasses the usage of this line force element is shown and is compared with an alternative implementation using a MultiBody.Joints.Assemblies.JointUPS component. The composition diagram of this example is displayed in the figure below.
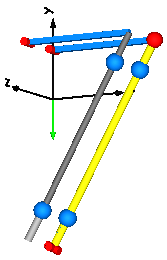
The animation view at time = 0 is shown in the next figure. The system on the left side in the front is the animation with the LineForceWithTwoMasses component whereas the system on the right side in the back is the animation with the JointUPS component. Both implementations yield the same result. However, the implementation with the LineForceWithTwoMasses component is simpler.
In the translational library there is the implicit assumption that forces of components that have only one flange connector act with opposite sign on the bearings of the component. This assumption is also used in the LineForceWithTwoMasses component: If a connection is present to only one of the flange connectors, then the force in this flange connector acts implicitly with opposite sign also in the other flange connector.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | animate | true | = true, if animation shall be enabled |
| Boolean | animateMasses | true | = true, if point masses shall be visualized provided animate=true and m_a, m_b > 0 |
| SI.Mass | m_a | 0 | Mass of point mass a on the connection line between the origin of frame_a and the origin of frame_b |
| SI.Mass | m_b | 0 | Mass of point mass b on the connection line between the origin of frame_a and the origin of frame_b |
| SI.Position | L_a | 0 | Distance between point mass a and frame_a (positive, if in direction of frame_b) |
| SI.Position | L_b | L_a | Distance between point mass b and frame_b (positive, if in direction of frame_a) |
| Advanced | |||
| SI.Distance | s_small (from LineForceBase) | 1e-10 | Prevent zero-division if distance between frame_a and frame_b is zero |
| Advanced › If enabled, can give wrong results, see MultiBody.UsersGuide.Tutorial.ConnectionOfLineForces | |||
| Boolean | fixedRotationAtFrame_a (from LineForceBase) | false | = true, if rotation frame_a.R is fixed (to directly connect line forces) |
| Boolean | fixedRotationAtFrame_b (from LineForceBase) | false | = true, if rotation frame_b.R is fixed (to directly connect line forces) |
| Animation › Cylinder at frame_a if animate = true | |||
| SI.Length | cylinderLength_a | 2*L_a | Length of cylinder at frame_a |
| Animation › Cylinder at frame_b if animate = true | |||
| SI.Length | cylinderLength_b | 2*L_b | Length of cylinder at frame_b |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Interfaces.Frame_a | frame_a (from PartialTwoFrames) | Coordinate system a fixed to the component with one cut-force and cut-torque | |
| Interfaces.Frame_b | frame_b (from PartialTwoFrames) | Coordinate system b fixed to the component with one cut-force and cut-torque | |
| Modelica.Mechanics.Translational.Interfaces.Flange_a | flange_b | 1-dim. translational flange (connect force of Translational library between flange_a and flange_b) | |
| Modelica.Mechanics.Translational.Interfaces.Flange_b | flange_a | 1-dim. translational flange (connect force of Translational library between flange_a and flange_b) |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Distance | length (from LineForceBase) | Distance between the origin of frame_a and the origin of frame_b | |
| SI.Position | s (from LineForceBase) | (Guarded) distance between the origin of frame_a and the origin of frame_b (>= s_small)) | |
| SI.Position[3] | r_rel_0 (from LineForceBase) | Position vector from frame_a to frame_b resolved in world frame | |
| Real[3] | e_rel_0 (from LineForceBase) | Unit vector in direction from frame_a to frame_b, resolved in world frame | |
| Types.SpecularCoefficient | specularCoefficient | world.defaultSpecularCoefficient | Reflection of ambient light (= 0: light is completely absorbed) |
| SI.Diameter | cylinderDiameter_a | world.defaultForceWidth | Diameter of cylinder at frame_a |
| Types.Color | color_a | {155, 155, 155} | Color of cylinder at frame_a |
| Real | diameterFraction | 0.8 | Diameter of cylinder at frame_b with respect to diameter of cylinder at frame_a |
| Types.Color | color_b | {100, 100, 100} | Color of cylinder at frame_b |
| Real | massDiameterFaction | 1.7 | Diameter of point mass spheres with respect to cylinderDiameter_a |
| Types.Color | massColor | Modelica.Mechanics.MultiBody.Types.Defaults.BodyColor | Color of point masses |