modelCylinder_analytic_CAD
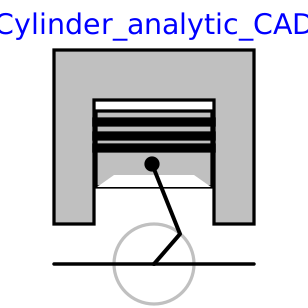
One cylinder with analytic handling of kinematic loop and CAD visualization
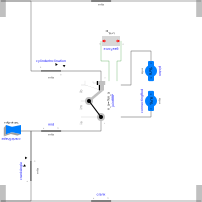
Extends from CylinderBase (One cylinder with analytic handling of kinematic loop).
Information
Slider-crank mechanism with analytic handling of kinematic loop to model one cylinder in an engine.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | animation (from CylinderBase) | true | = true, if animation shall be enabled |
| SI.Length | cylinderTopPosition (from CylinderBase) | 0.42 | Length from crank shaft to end of cylinder. |
| SI.Length | crankLength (from CylinderBase) | 0.14 | Length of crank shaft in x direction |
| SI.Length | crankPinOffset (from CylinderBase) | 0.05 | Offset of crank pin from center axis |
| SI.Length | crankPinLength (from CylinderBase) | 0.1 | Offset of crank pin from center axis |
| Modelica.Units.NonSI.Angle_deg | cylinderInclinationAngle (from CylinderBase) | 0 | Inclination of cylinder |
| Modelica.Units.NonSI.Angle_deg | crankAngleOffset (from CylinderBase) | 0 | Offset for crank angle |
| SI.Length | cylinderLength (from CylinderBase) | cylinderTopPosition - (pistonLength + rodLength - crankPinOffset) | Maximum length of cylinder volume |
| Piston | |||
| SI.Length | pistonLength (from CylinderBase) | 0.1 | Length of cylinder |
| SI.Length | pistonCenterOfMass (from CylinderBase) | pistonLength/2 | Distance from frame_a to center of mass of piston |
| SI.Mass | pistonMass (from CylinderBase) | 6 | Mass of piston |
| SI.Inertia | pistonInertia_11 (from CylinderBase) | 0.0088 | Inertia 11 of piston with respect to center of mass frame, parallel to frame_a |
| SI.Inertia | pistonInertia_22 (from CylinderBase) | 0.0076 | Inertia 22 of piston with respect to center of mass frame, parallel to frame_a |
| SI.Inertia | pistonInertia_33 (from CylinderBase) | 0.0088 | Inertia 33 of piston with respect to center of mass frame, parallel to frame_a |
| Rod | |||
| SI.Length | rodLength (from CylinderBase) | 0.175 | Length of rod |
| SI.Length | rodCenterOfMass (from CylinderBase) | rodLength/2 | Distance from frame_a to center of mass of piston |
| SI.Mass | rodMass (from CylinderBase) | 1 | Mass of rod |
| SI.Inertia | rodInertia_11 (from CylinderBase) | 0.006 | Inertia 11 of rod with respect to center of mass frame, parallel to frame_a |
| SI.Inertia | rodInertia_22 (from CylinderBase) | 0.0005 | Inertia 22 of rod with respect to center of mass frame, parallel to frame_a |
| SI.Inertia | rodInertia_33 (from CylinderBase) | 0.006 | Inertia 33 of rod with respect to center of mass frame, parallel to frame_a |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Interfaces.Frame_a | cylinder_a (from CylinderBase) | ||
| Interfaces.Frame_a | cylinder_b (from CylinderBase) | ||
| Interfaces.Frame_a | crank_a (from CylinderBase) | ||
| Interfaces.Frame_a | crank_b (from CylinderBase) |