
modelGyroscopicEffects
Extends from Modelica.Icons.Example (Icon for runnable examples).
Information
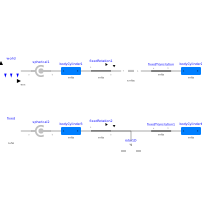
This example consists of a body that is attached to the world system with a spherical joint. On this body, a "rotor", i.e., a body with rotational symmetry is present. Two kinds of models are shown:
- In the upper part of the diagram layer, only multi-body components are used.
- In the lower part of the diagram layer, the same model is implemented, but by a different modeling of the cylindrical body: The cylindrical body is included, but it is rigidly attached to its mount. This part takes into account the movement of the center of mass and of the inertia tensor of the cylindrical body. Note, since the cylindrical body has rotational symmetry, its center of mass and its inertia tensor is independent of the angle of the inertia and can therefore be rigidly attached to its mount. Additionally, with a "MultiBody.Parts.Rotor1D" model, a primarily 1-dim. inertia is included that takes into account the additional effects when the cylindrical body is moving relatively to its mounts
The simulation reveals that both the kinematic movement and the reaction forces on the environment (object "world" and "fixed" respectively) are identical for both models.
A typical usage scenario is to model a complete drive train of a vehicle, including the automatic gearbox, with elements of the "Mechanics.Rotational" library, but using the "Rotor1D" model instead of the "Rotational.Components.Inertia" component. This drive train model can be mounted on a 3-dim. multi-body model of the vehicle. Additionally, one rigid body has to be fixed to the vehicle that has the mass, center of mass and inertia tensor of the complete drive train. Both models together, give exactly the same effect, as if every part of the drive train would have been modelled solely with mult-body components. One benefit of this modeling is that the simulation is much faster.
Components
| Type | Name | Default | Description |
|---|---|---|---|
| World | world | ||
| Joints.Spherical | spherical1 | ||
| Parts.BodyCylinder | bodyCylinder1 | ||
| Parts.FixedRotation | fixedRotation1 | ||
| Joints.Revolute | revolute | ||
| Parts.FixedTranslation | fixedTranslation | ||
| Parts.BodyCylinder | bodyCylinder2 | ||
| Parts.Fixed | fixed | ||
| Joints.Spherical | spherical2 | ||
| Parts.BodyCylinder | bodyCylinder3 | ||
| Parts.FixedRotation | fixedRotation2 | ||
| Parts.FixedTranslation | fixedTranslation1 | ||
| Parts.BodyCylinder | bodyCylinder4 | ||
| Parts.Rotor1D | rotor1D |