modelAxisType2
Axis model of the r3 joints 4,5,6
Information
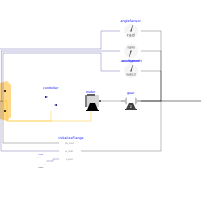
The axis model consists of the controller, the motor including current controller and the gearbox including gear elasticity and bearing friction. The only difference to the axis model of joints 4,5,6 (= model axisType2) is that elasticity and damping in the gear boxes are not neglected.
The input signals of this component are the desired angle and desired angular velocity of the joint. The reference signals have to be "smooth" (position has to be differentiable at least 2 times). Otherwise, the gear elasticity leads to significant oscillations.
Default values of the parameters are given for the axis of joint 1.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Controller | |||
| Real | kp | 10 | Gain of position controller |
| Real | ks | 1 | Gain of speed controller |
| SI.Time | Ts | 0.01 | Time constant of integrator of speed controller |
| Motor | |||
| Real | k | 1.1616 | Gain of motor |
| Real | w | 4590 | Time constant of motor |
| Real | D | 0.6 | Damping constant of motor |
| SI.Inertia | J | 0.0013 | Moment of inertia of motor |
| Gear | |||
| Real | ratio | -105 | Gear ratio |
| SI.Torque | Rv0 | 0.4 | Viscous friction torque at zero velocity |
| Real | Rv1 | (0.13/160) | Viscous friction coefficient |
| Real | peak | 1 | Maximum static friction torque is peak*Rv0 (peak >= 1) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.Rotational.Interfaces.Flange_b | flange | ||
| Modelica.Mechanics.MultiBody.Examples.Systems.RobotR3.Utilities.AxisControlBus | axisControlBus |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| GearType2 | gear | ||
| Motor | motor | ||
| Controller | controller | ||
| Modelica.Mechanics.Rotational.Sensors.AngleSensor | angleSensor | ||
| Modelica.Mechanics.Rotational.Sensors.SpeedSensor | speedSensor | ||
| Modelica.Mechanics.Rotational.Sensors.AccSensor | accSensor | ||
| Modelica.Mechanics.Rotational.Components.InitializeFlange | initializeFlange | ||
| Blocks.Sources.Constant | const |