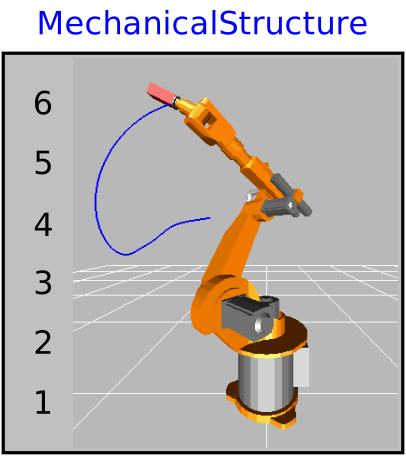
modelMechanicalStructure

Model of the mechanical part of the r3 robot (without animation)
Information

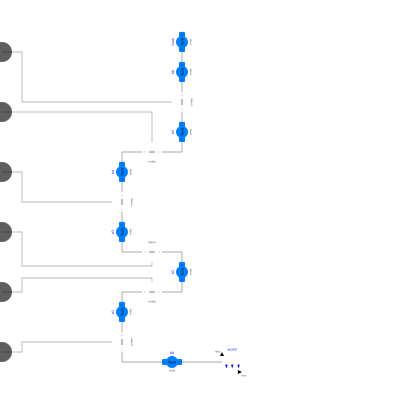
This model contains the mechanical components of the r3 robot (multibody system).

Parameters

TypeNameDefaultDescription
Booleananimationtrue= true, if animation shall be enabled
SI.MassmLoad15Mass of load
SI.Position[3]rLoad{0, 0.25, 0}Distance from last flange to load mass
SI.Accelerationg9.81Gravity acceleration

Connectors

TypeNameDefaultDescription
Modelica.Mechanics.Rotational.Interfaces.Flange_aaxis1
Modelica.Mechanics.Rotational.Interfaces.Flange_aaxis2
Modelica.Mechanics.Rotational.Interfaces.Flange_aaxis3
Modelica.Mechanics.Rotational.Interfaces.Flange_aaxis4
Modelica.Mechanics.Rotational.Interfaces.Flange_aaxis5
Modelica.Mechanics.Rotational.Interfaces.Flange_aaxis6

Components

TypeNameDefaultDescription
SI.Angle[6]qJoint angles
SI.AngularVelocity[6]qdJoint speeds
SI.AngularAcceleration[6]qddJoint accelerations
SI.Torque[6]tauJoint driving torques
Modelica.Mechanics.MultiBody.Worldworld
Modelica.Mechanics.MultiBody.Joints.Revoluter1
Modelica.Mechanics.MultiBody.Joints.Revoluter2
Modelica.Mechanics.MultiBody.Joints.Revoluter3
Modelica.Mechanics.MultiBody.Joints.Revoluter4
Modelica.Mechanics.MultiBody.Joints.Revoluter5
Modelica.Mechanics.MultiBody.Joints.Revoluter6
Modelica.Mechanics.MultiBody.Parts.BodyShapeb0
Modelica.Mechanics.MultiBody.Parts.BodyShapeb1
Modelica.Mechanics.MultiBody.Parts.BodyShapeb2
Modelica.Mechanics.MultiBody.Parts.BodyShapeb3
Modelica.Mechanics.MultiBody.Parts.BodyShapeb4
Modelica.Mechanics.MultiBody.Parts.BodyShapeb5
Modelica.Mechanics.MultiBody.Parts.BodyShapeb6
Modelica.Mechanics.MultiBody.Parts.BodyShapeload