modelJointRRR
Extends from Interfaces.PartialTwoFramesDoubleSize (Base model for components providing two frame connectors + outer world + assert to guarantee that the component is connected (default icon size is factor 2 larger as usual)).
Information
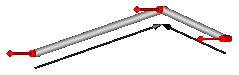
This component consists of 3 revolute joints with parallel axes of rotation that are connected together by two rods, see the default animation in the following figure (the axes vectors are not part of the default animation):
This joint aggregation introduces neither constraints nor state variables and should therefore be used in kinematic loops whenever possible to avoid non-linear systems of equations. It is only meaningful to use this component in planar loops. Basically, the position and orientation of the 3 revolute joints as well as of frame_ia, frame_ib, and frame_im are calculated by solving analytically a non-linear equation, given the position and orientation at frame_a and at frame_b.
Connector frame_a is the "left" side of the first revolute joint whereas frame_ia is the "right side of this revolute joint, fixed in rod 1. Connector frame_b is the "right" side of the third revolute joint whereas frame_ib is the "left" side of this revolute joint, fixed in rod 2. Finally, connector frame_im is the connector at the "right" side of the revolute joint in the middle, fixed in rod 2.
The easiest way to define the parameters of this joint is by moving the MultiBody system in a reference configuration where all frames of all components are parallel to each other (alternatively, at least frame_a, frame_ia, frame_im, frame_ib, frame_b of the JointRRR joint should be parallel to each other when defining an instance of this component).
Basically, the JointRRR model consists internally of a universal - spherical - revolute joint aggregation (= JointUSR). In a planar loop this will behave as if 3 revolute joints with parallel axes are connected by rigid rods.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | animation | true | = true, if animation shall be enabled |
| Modelica.Mechanics.MultiBody.Types.Axis | n_a | {0, 0, 1} | Axes of revolute joints resolved in frame_a (all axes are parallel to each other) |
| Real[3] | n_b | Axis of revolute joint fixed and resolved in frame_b | |
| SI.Position[3] | rRod1_ia | {1, 0, 0} | Vector from origin of frame_a to revolute joint in the middle, resolved in frame_ia |
| SI.Position[3] | rRod2_ib | {-1, 0, 0} | Vector from origin of frame_ib to revolute joint in the middle, resolved in frame_ib |
| Modelica.Units.NonSI.Angle_deg | phi_offset | 0 | Relative angle offset of revolute joint at frame_b (angle = phi(t) + from_deg(phi_offset)) |
| Modelica.Units.NonSI.Angle_deg | phi_guess | 0 | Select the configuration such that at initial time |phi(t0) - from_deg(phi_guess)| is minimal |
| Real[3] | e_a | Modelica.Math.Vectors.normalizeWithAssert(n_a) | Unit vector along axes of rotations, resolved in frame_a |
| Real[3] | e_ia | jointUSR.e2_ia | Unit vector along axes of rotations, resolved in frame_ia |
| Real[3] | e_b | jointUSR.revolute.e | Unit vector along axes of rotations, resolved in frame_b, frame_ib and frame_im |
| Animation › if animation = true | |||
| SI.Distance | cylinderLength | world.defaultJointLength | Length of cylinders representing the revolute joints |
| SI.Distance | cylinderDiameter | world.defaultJointWidth | Diameter of cylinders representing the revolute joints |
| SI.Diameter | rodDiameter | 1.1*cylinderDiameter | Diameter of the two rods connecting the revolute joints |
| Advanced | |||
| Boolean | checkTotalPower | false | = true, if total power flowing into this component shall be determined (must be zero) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Interfaces.Frame_a | frame_a (from PartialTwoFramesDoubleSize) | Coordinate system fixed to the component with one cut-force and cut-torque | |
| Interfaces.Frame_b | frame_b (from PartialTwoFramesDoubleSize) | Coordinate system fixed to the component with one cut-force and cut-torque | |
| Modelica.Mechanics.MultiBody.Interfaces.Frame_a | frame_ia | Coordinate system at origin of frame_a fixed at connecting rod of left and middle revolute joint | |
| Modelica.Mechanics.MultiBody.Interfaces.Frame_b | frame_ib | Coordinate system at origin of frame_b fixed at connecting rod of middle and right revolute joint | |
| Modelica.Mechanics.MultiBody.Interfaces.Frame_b | frame_im | Coordinate system at origin of revolute joint in the middle fixed at connecting rod of middle and right revolute joint | |
| Modelica.Mechanics.Rotational.Interfaces.Flange_a | axis | 1-dim. rotational flange that drives the right revolute joint at frame_b | |
| Modelica.Mechanics.Rotational.Interfaces.Flange_b | bearing | 1-dim. rotational flange of the drive bearing of the right revolute joint at frame_b |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Types.Color | cylinderColor | Modelica.Mechanics.MultiBody.Types.Defaults.JointColor | Color of cylinders representing the revolute joints |
| Types.Color | rodColor | Modelica.Mechanics.MultiBody.Types.Defaults.RodColor | Color of the two rods connecting the revolute joint |
| Types.SpecularCoefficient | specularCoefficient | world.defaultSpecularCoefficient | Reflection of ambient light (= 0: light is completely absorbed) |
| SI.Power | totalPower | jointUSR.totalPower | Total power flowing into this element, if checkTotalPower=true (otherwise dummy) |
| JointUSR | jointUSR |