modelFixedFrame
Visualizing a coordinate system including axes labels (visualization data may vary dynamically)
Extends from Modelica.Mechanics.MultiBody.Interfaces.PartialVisualizer (Base model for visualizers (has a frame_a on the left side + outer world + assert to guarantee that the component is connected)).
Information
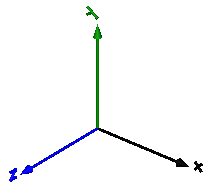
Model FixedFrame visualizes the three axes of
its coordinate system frame_a together with appropriate axes
labels. A typical example is shown in the following figure:
The sizes of the axes, the axes colors and the specular coefficient (= reflection factor for ambient light) can vary dynamically by providing appropriate expressions in the input fields of the parameter menu.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | animation | true | = true, if animation shall be enabled |
| if animation = true | |||
| Boolean | showLabels | true | = true, if labels shall be shown |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Interfaces.Frame_a | frame_a (from PartialVisualizer) | Coordinate system in which visualization data is resolved |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Distance | length | 0.5 | Length of axes arrows |
| SI.Distance | diameter | length/world.defaultFrameDiameterFraction | Diameter of axes arrows |
| Types.Color | color_x | Modelica.Mechanics.MultiBody.Types.Defaults.FrameColor | Color of x-arrow |
| Types.Color | color_y | color_x | Color of y-arrow |
| Types.Color | color_z | color_x | Color of z-arrow |
| Types.SpecularCoefficient | specularCoefficient | world.defaultSpecularCoefficient | Reflection of ambient light (= 0: light is completely absorbed) |