modelVoluminousWheel
Visualizing a voluminous wheel
Extends from Modelica.Mechanics.MultiBody.Interfaces.PartialVisualizer (Base model for visualizers (has a frame_a on the left side + outer world + assert to guarantee that the component is connected)).
Information
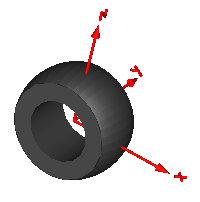
Model VoluminousWheel provides a simple visualization of a tire using a torus and a pipe shape object. The center of the wheel is located at connector frame_a (visualized by the red coordinate system in the figure below).
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | animation | true | = true, if animation shall be enabled |
| SI.Radius | rTire | 0.25 | Radius of the tire |
| SI.Radius | rRim | 0.14 | Radius of the rim |
| SI.Radius | width | 0.25 | Width of the tire |
| SI.Radius | rCurvature | 0.30 | Radius of the tire's cross section |
| Material properties | |||
| Modelica.Mechanics.MultiBody.Types.RealColor | color | {64, 64, 64} | Color of tire |
| Types.SpecularCoefficient | specularCoefficient | 0.5 | Reflection of ambient light (= 0: light is completely absorbed) |
| Discretization | |||
| Integer | n_rTire | 40 | Number of points along rTire |
| Integer | n_rCurvature | 20 | Number of points along rCurvature |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Interfaces.Frame_a | frame_a (from PartialVisualizer) | Coordinate system in which visualization data is resolved |
Revisions
- July 2010 by Martin Otter
Adapted to the new Surface model. - July 2005 by Dirk Zimmer (practical training at DLR)
First version to visualize a multi-level tyre wheel model.