
modelBodyShape
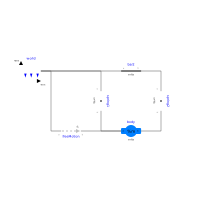
Simple spring/damper/mass system
Extends from Icons.Example (Icon for runnable examples).
Information
This is the same example as "FreeBody". The only difference is that with the FreeMotion joint explicitly 6 degrees of freedom are introduced. The advantage is that no non-linear system of equations occurs any more, because the FreeMotion joint is described by a set of non-redundant variables. The disadvantage is that there is an orientation for which this description is singular (see description of FreeMotion joint). In technical systems it is often possible to use the FreeMotion joint such that the singularity
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | animation | true | = true, if animation shall be enabled |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| MultiBody.World | world | ||
| MultiBody.Parts.FixedTranslation | bar2 | ||
| MultiBody.Forces.Spring | spring1 | ||
| MultiBody.Parts.BodyShape | body | ||
| MultiBody.Forces.Spring | spring2 | ||
| MultiBody.Joints.FreeMotion | freeMotion |