modelController
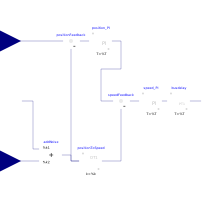
Information
A motor controller
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Interfaces.RealInput | positionMeasured | Position signal of motor | |
| Modelica.Blocks.Interfaces.RealInput | positionReference | Reference position | |
| Modelica.Blocks.Interfaces.RealOutput | y1 | Connector of Real output signal |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Continuous.PI | speed_PI | ||
| Modelica.Blocks.Math.Feedback | speedFeedback | ||
| Modelica.Blocks.Continuous.Derivative | positionToSpeed | ||
| Modelica.Blocks.Continuous.PI | position_PI | ||
| Modelica.Blocks.Math.Feedback | positionFeedback | ||
| Modelica.Blocks.Math.Add | addNoise | ||
| Noise.Examples.Actuator.Parts.NoNoise | noiseModel | ||
| Modelica.Blocks.Continuous.FirstOrder | busdelay |
Revisions
 Developed 2014 at the DLR Institute of System Dynamics and Control