modelKinematicLoop
An example of a kinematic loop (manual state selection)
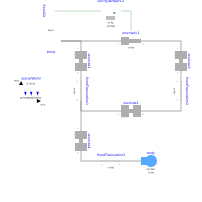
Extends from Modelica.Icons.Example (Icon for runnable examples).
Information
In this version, the states are manually selected.
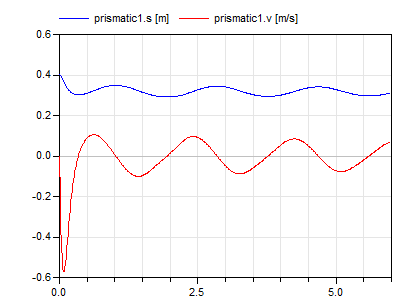
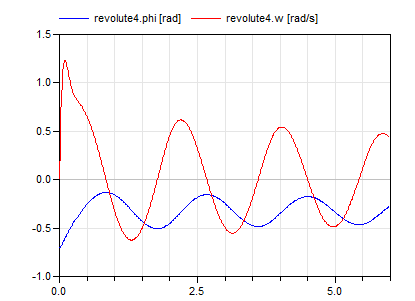
Selected continuous time states
- revolute1.phi
- revolute1.w
- revolute4.phi
- revolute4.w
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Joints.Revolute | revolute1 | ||
| Joints.Revolute | revolute3 | ||
| Joints.Revolute | revolute2 | ||
| Joints.Revolute | revolute4 | ||
| Joints.Prismatic | prismatic1 | ||
| Modelica.Mechanics.Translational.Components.SpringDamper | springDamper1D | ||
| Parts.Body | body | ||
| Parts.FixedTranslation | fixedTranslation1 | ||
| Parts.FixedTranslation | fixedTranslation2 | ||
| Parts.FixedTranslation | fixedTranslation3 | ||
| Parts.Fixed | fixed | ||
| Modelica.Mechanics.Translational.Components.Fixed | fixed1D | ||
| PlanarWorld | planarWorld |
Revisions
 Developed 2010 at the DLR Institute of System Dynamics and Control