modelKinematicLoop_DynamicStateSelection
An example of a kinematic loop
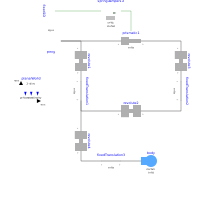
Extends from Modelica.Icons.Example (Icon for runnable examples).
Information
In this version, the states are not manually set but might be dynamically selected by the simulation environment.
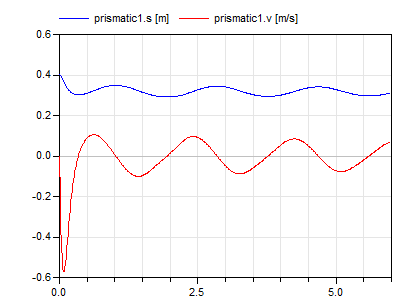
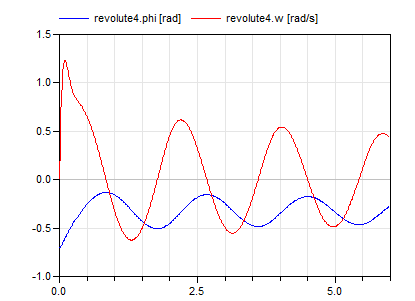
Selected continuous time states
- There are 2 sets of dynamic state selection.
- From set 1 there there are 2 states to be selected from:
- body.frame_a.phi
- revolute2.phi
- revolute4.phi
- springDamper.s_rel
- From set 2 there there are 2 states to be selected from:
- body.w
- revolute2.w
- revolute4.w
- springDamper.v_rel
- From set 1 there there are 2 states to be selected from:
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Joints.Revolute | revolute1 | ||
| Joints.Revolute | revolute3 | ||
| Joints.Revolute | revolute2 | ||
| Joints.Revolute | revolute4 | ||
| Joints.Prismatic | prismatic1 | ||
| Modelica.Mechanics.Translational.Components.SpringDamper | springDamper1D | ||
| Parts.Body | body | ||
| Parts.FixedTranslation | fixedTranslation1 | ||
| Parts.FixedTranslation | fixedTranslation2 | ||
| Parts.FixedTranslation | fixedTranslation3 | ||
| Parts.Fixed | fixed | ||
| Modelica.Mechanics.Translational.Components.Fixed | fixed1D | ||
| PlanarWorld | planarWorld |
Revisions
 Developed 2010 at the DLR Institute of System Dynamics and Control