
modelWheelBasedCraneCrab
A pendulum mounted on an ideal rolling wheel
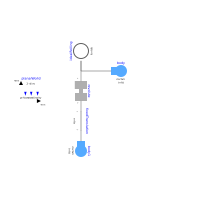
Extends from Modelica.Icons.Example (Icon for runnable examples).
Information
This model contains non-holonomic constraints.
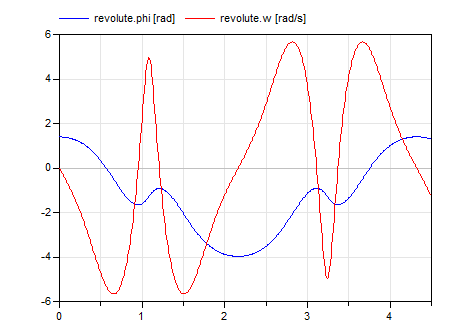
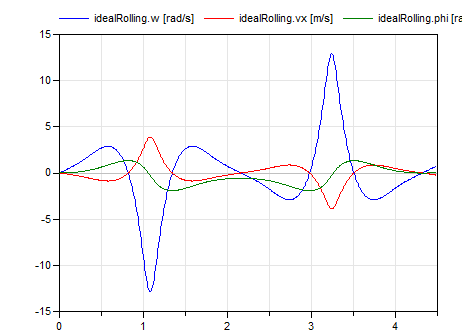
Selected continuous time states
- body1.frame_a.phi
- body1.r[1]
- body1.w
- revolute.phi
- revolute.w
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Joints.IdealRolling | idealRolling | ||
| Parts.Body | body | ||
| Joints.Revolute | revolute | ||
| Parts.FixedTranslation | fixedTranslation | ||
| Parts.Body | body1 | ||
| PlanarWorld | planarWorld |
Revisions
 Developed 2010 at the DLR Institute of System Dynamics and Control