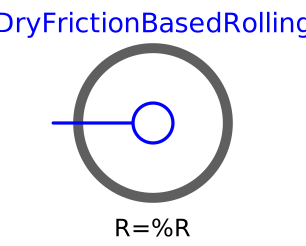
modelDryFrictionBasedRolling
A joint representing a wheel with slip-based rolling (dry friction law) on the x-axis
Extends from Modelica.Thermal.HeatTransfer.Interfaces.PartialElementaryConditionalHeatPort (Partial model to include a conditional HeatPort in order to dissipate losses, used for textual modeling, i.e., for elementary models).
Information
This model contains only one mechanical connector frame_a lying
at the center of the wheel, where slip occurs between the wheel and ground
and force caused by that is also taken into account.
The corresponding power loss (variable lossPower) is
transferred to the heatPort connector.
The ground is hereby represented by the x-axis.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | useHeatPort (from PartialElementaryConditionalHeatPort) | false | = true, if heatPort is enabled |
| SI.Temperature | T (from PartialElementaryConditionalHeatPort) | 293.15 | Fixed device temperature if useHeatPort = false |
| SI.Length | R | 1.0 | Radius of the wheel |
| SI.Velocity | vAdhesion | Adhesion velocity | |
| SI.Velocity | vSlide | Sliding velocity | |
| Real | mu_A | Friction coefficient at adhesion | |
| Real | mu_S | Friction coefficient at sliding | |
| Advanced | |||
| StateSelect | stateSelect | StateSelect.default | Priority to use phi, w and a as states |
| Animation | |||
| Boolean | animate | true | Enable animation |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| HeatTransfer.Interfaces.HeatPort_a | heatPort (from PartialElementaryConditionalHeatPort) | Optional port to which dissipated losses are transported in form of heat | |
| Interfaces.Frame_a | frame_a |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Power | lossPower (from PartialElementaryConditionalHeatPort) | Loss power leaving component via heatPort (> 0, if heat is flowing out of component) | |
| SI.Temperature | TheatPort (from PartialElementaryConditionalHeatPort) | Temperature of heatPort | |
| PlanarWorld | planarWorld | Planar world model | |
| SI.Position | x | Horizontal position | |
| SI.Angle | phi | Angular position | |
| SI.AngularVelocity | w | Angular velocity | |
| SI.AngularAcceleration | z | Angular acceleration | |
| SI.Velocity | vx | Velocity in x-direction | |
| SI.Force | N | Normal force | |
| SI.Velocity | v_slip | Slip velocity | |
| MB.Visualizers.Advanced.Shape | cylinder | ||
| MB.Visualizers.Advanced.Shape | rim1 | ||
| MB.Visualizers.Advanced.Shape | rim2 |
Revisions
 Developed 2010 at the DLR Institute of System Dynamics and Control