modelIdealRolling
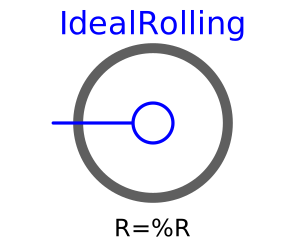
A joint representing a wheel ideally rolling on the x-axis
Information
This model contains only one connector frame_a lying at the center
of the wheel, where it is assumed that no slip occurs between the wheel and ground.
The ground is hereby represented by the x-axis.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Length | R | 1.0 | Radius of the wheel |
| Advanced | |||
| StateSelect | stateSelect | StateSelect.default | Priority to use phi, w and a as states |
| Animation | |||
| Boolean | animate | true | Enable animation |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Interfaces.Frame_a | frame_a |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| PlanarWorld | planarWorld | Planar world model | |
| SI.Position | x | Horizontal position | |
| SI.Angle | phi | Angular position | |
| SI.AngularVelocity | w | Angular velocity | |
| SI.AngularAcceleration | z | Angular acceleration | |
| SI.Velocity | vx | Velocity in x-direction | |
| MB.Visualizers.Advanced.Shape | cylinder | ||
| MB.Visualizers.Advanced.Shape | rim1 | ||
| MB.Visualizers.Advanced.Shape | rim2 |
Revisions
 Developed 2010 at the DLR Institute of System Dynamics and Control