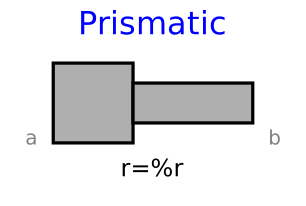
modelPrismatic
Extends from PlanarMechanics.Interfaces.PartialTwoFrames (Partial model with two frames).
Information
Direction of the prismatic joint is determined by r[2],
which is a vector pointing from frame_a to
frame_b.
Optionally, two additional one-dimensional mechanical flanges (flange
flange_a represents the driving flange and flange
support represents the bearing) can be enabled via
parameter useFlange. The enabled flange_a
flange can be driven with elements of the
Modelica.Mechanics.Translational
library.
In the "Initialization" block, elongation s
of the joint, velocity of elongation v as well as
acceleration of elongation a can be initialized.
It can be defined via parameter (in "Advanced" tab)
stateSelect that the relative distance s
and its derivative shall be definitely used as states by setting
stateSelect = StateSelect.always.
In "Animation" group, animation parameters for this model can be set,
where zPosition represents the model's position along
the z axis in 3D animation. Some of the values can be preset
by an outer PlanarWorld
model.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | useFlange | false | = true, if force flange enabled, otherwise implicitly grounded |
| Boolean | animate | true | = true, if animation shall be enabled |
| SI.Position[2] | r | Direction of the rod wrt. body system at phi=0 | |
| SI.Length | l | Modelica.Math.Vectors.length(r) | Length of r |
| Real[2] | e | Modelica.Math.Vectors.normalizeWithAssert(r) | Unit vector in direction of r |
| Advanced | |||
| StateSelect | stateSelect | StateSelect.default | Priority to use s and v as states |
| Animation › if animation = true | |||
| SI.Length | zPosition | planarWorld.defaultZPosition | Position z of the prismatic joint box |
| SI.Distance | boxWidth | l/planarWorld.defaultWidthFraction | Width of prismatic joint box |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Frame_a | frame_a (from PartialTwoFrames) | Coordinate system fixed to the component with one cut-force and cut-torque | |
| Frame_b | frame_b (from PartialTwoFrames) | Coordinate system fixed to the component with one cut-force and cut-torque | |
| Modelica.Mechanics.Translational.Interfaces.Flange_a | flange_a | ||
| Modelica.Mechanics.Translational.Interfaces.Flange_b | support | 1-dim. translational flange of the drive support (assumed to be fixed in the world frame, NOT in the joint) |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| MB.Types.Color | boxColor | Types.Defaults.JointColor | Color of prismatic joint box |
| MB.Types.SpecularCoefficient | specularCoefficient | planarWorld.defaultSpecularCoefficient | Reflection of ambient light (= 0: light is completely absorbed) |
| SI.Position | s | Elongation of the joint | |
| SI.Velocity | v | Velocity of elongation | |
| SI.Acceleration | a | Acceleration of elongation | |
| SI.Force | f | Force in direction of elongation | |
| Real[2] | e0 | Unit vector in direction of r resolved w.r.t. inertial frame | |
| SI.Position[2] | r0 | Translation vector of the prismatic rod resolved w.r.t. inertial frame | |
| Real[2,2] | R | Rotation matrix | |
| MB.Visualizers.Advanced.Shape | box |
Revisions
 Developed 2010 at the DLR Institute of System Dynamics and Control