modelAbsoluteVelocity
Extends from Internal.PartialAbsoluteSensor (Partial absolute sensor model for sensors defined by components).
Information
The absolute velocity vector of the origin of frame_a
is determined and provided at the output signal connector v.
Via parameter resolveInFrame it is defined, in which frame
the velocity vector is resolved.
| resolveInFrame = … | Output vector resolved in |
|---|---|
| Types.ResolveInFrameA.world | world frame |
| Types.ResolveInFrameA.frame_a | frame_a |
| Types.ResolveInFrameA.frame_resolve | frame_resolve (must be connected) |
If resolveInFrame = Types.ResolveInFrameA.frame_resolve,
the conditional connector frame_resolve is enabled
and v is resolved in the frame, to which
frame_resolve is connected.
Note, if this connector is enabled, it must be connected.
Example: If resolveInFrame = Types.ResolveInFrameA.frame_resolve,
the output vector is computed as:
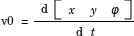
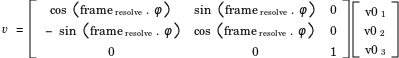
where [x y φ]
is position and angle vector of origin of frame_a resolved
in world frame.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.MultiBody.Types.ResolveInFrameA | resolveInFrame | Modelica.Mechanics.MultiBody.Types.ResolveInFrameA.frame_a | Frame in which output vector v shall be resolved (1: world, 2: frame_a, 3: frame_resolve) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Interfaces.Frame_a | frame_a (from PartialAbsoluteSensor) | Coordinate system at which the kinematic quantities are measured | |
| Modelica.Blocks.Interfaces.RealOutput[3] | v | Vector of absolute measurements of frame_a on velocity level, resolved in frame defined by resolveInFrame | |
| Interfaces.Frame_resolve | frame_resolve | Coordinate system in which output vector v is optionally resolved |
Revisions
 Developed 2010 at the DLR Institute of System Dynamics and Control