modelCutForce
Extends from Internal.PartialCutForceSensor (Base model to measure the cut force and/or torque between two frames, defined by components).
Information
The cut-force acting between the two frames to which this model
is connected, is determined and provided at the output signal
connector force (= frame_a.f).
If parameter positiveSign = false, the negative
cut-force is provided (= frame_b.f).
Via parameter resolveInFrame it is defined, in which frame
the force vector is resolved.
| resolveInFrame = … | Output vector resolved in |
|---|---|
| Types.ResolveInFrameAB.world | world frame |
| Types.ResolveInFrameAB.frame_a | frame_a |
| Types.ResolveInFrameAB.frame_b | frame_b |
| Types.ResolveInFrameAB.frame_resolve | frame_resolve (must be connected) |
If resolveInFrame = Types.ResolveInFrameAB.frame_resolve,
the conditional connector frame_resolve is enabled and
output force is resolved in the frame, to which
frame_resolve is connected.
Note, if this connector is enabled, it must be connected.
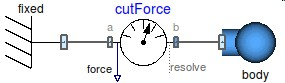
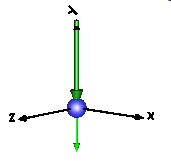
In the following figure the modeling and animation of this sensor is shown.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | animation | true | = true, if animation shall be enabled (show arrow) |
| Boolean | positiveSign | true | = true, if force with positive sign is returned (= frame_a.f), otherwise with negative sign (= frame_b.f) |
| Modelica.Mechanics.MultiBody.Types.ResolveInFrameA | resolveInFrame (from PartialCutForceSensor) | Modelica.Mechanics.MultiBody.Types.ResolveInFrameA.frame_a | Frame in which output vector(s) is/are resolved (1: world, 2: frame_a, 3: frame_resolve) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Interfaces.RealOutput[2] | force | Cut force resolved in frame defined by resolveInFrame | |
| Interfaces.Frame_a | frame_a (from PartialCutForceSensor) | Coordinate system a | |
| Interfaces.Frame_b | frame_b (from PartialCutForceSensor) | Coordinate system b | |
| Interfaces.Frame_resolve | frame_resolve (from PartialCutForceSensor) | Output vectors are optionally resolved in this frame (cut-force/-torque are set to zero) |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Real | N_to_m | planarWorld.defaultN_to_m | Force arrow scaling (length = force/N_to_m) |
| SI.Diameter | forceDiameter | planarWorld.defaultArrowDiameter | Has no longer an effect and is only kept for backwards compatibility (arrow visualization by Vector now) |
| MB.Types.Color | forceColor | PlanarMechanics.Types.Defaults.ForceColor | Color of force arrow |
| MB.Types.SpecularCoefficient | specularCoefficient | planarWorld.defaultSpecularCoefficient | Reflection of ambient light (= 0: light is completely absorbed) |
Revisions
 Developed 2010 at the DLR Institute of System Dynamics and Control