modelCutForceAndTorque
Extends from Internal.PartialCutForceSensor (Base model to measure the cut force and/or torque between two frames, defined by components).
Information
The cut-force and cut-torque acting between the two frames to which this
model is connected, are determined and provided at the output signal connectors
force (= frame_a.f) and torque
(= frame_a.t).
If parameter positiveSign = false, the negative
cut-force and cut-torque is provided (= frame_b.f, frame_b.t).
Via parameter resolveInFrame it is defined, in which frame
the force vector is resolved.
| resolveInFrame = … | Force vector resolved in |
|---|---|
| Types.ResolveInFrameAB.world | world frame |
| Types.ResolveInFrameAB.frame_a | frame_a |
| Types.ResolveInFrameAB.frame_b | frame_b |
| Types.ResolveInFrameAB.frame_resolve | frame_resolve (must be connected) |
If resolveInFrame = Types.ResolveInFrameAB.frame_resolve,
the conditional connector frame_resolve is enabled and
output force is resolved in the frame, to which
frame_resolve is connected.
Note, if this connector is enabled, it must be connected.
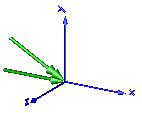
In the following figure the animation of the
sensor is shown. The dark blue coordinate system is frame_b,
and the green arrows are the cut force and the cut torque,
respectively, acting at frame_b and
with negative sign at frame_a.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | animation | true | = true, if animation shall be enabled (show force and torque arrow) |
| Boolean | positiveSign | true | = true, if force and torque with positive sign is returned (= frame_a.f/.t), otherwise with negative sign (= frame_b.f/.t) |
| Modelica.Mechanics.MultiBody.Types.ResolveInFrameA | resolveInFrame (from PartialCutForceSensor) | Modelica.Mechanics.MultiBody.Types.ResolveInFrameA.frame_a | Frame in which output vector(s) is/are resolved (1: world, 2: frame_a, 3: frame_resolve) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Interfaces.RealOutput[2] | force | Cut force resolved in frame defined by resolveInFrame | |
| Modelica.Blocks.Interfaces.RealOutput | torque | Cut torque resolved in frame defined by resolveInFrame | |
| Interfaces.Frame_a | frame_a (from PartialCutForceSensor) | Coordinate system a | |
| Interfaces.Frame_b | frame_b (from PartialCutForceSensor) | Coordinate system b | |
| Interfaces.Frame_resolve | frame_resolve (from PartialCutForceSensor) | Output vectors are optionally resolved in this frame (cut-force/-torque are set to zero) |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Real | N_to_m | planarWorld.defaultN_to_m | Force arrow scaling (length = force/N_to_m) |
| Real | Nm_to_m | planarWorld.defaultNm_to_m | Torque arrow scaling (length = torque/Nm_to_m) |
| SI.Diameter | forceDiameter | planarWorld.defaultArrowDiameter | Has no longer an effect and is only kept for backwards compatibility (arrow visualization by Vector now) |
| SI.Diameter | torqueDiameter | forceDiameter | Has no longer an effect and is only kept for backwards compatibility (arrow visualization by Vector now) |
| MB.Types.Color | forceColor | PlanarMechanics.Types.Defaults.ForceColor | Color of force arrow |
| MB.Types.Color | torqueColor | PlanarMechanics.Types.Defaults.TorqueColor | Color of torque arrow |
| MB.Types.SpecularCoefficient | specularCoefficient | planarWorld.defaultSpecularCoefficient | Reflection of ambient light (= 0: light is completely absorbed) |
Revisions
 Developed 2010 at the DLR Institute of System Dynamics and Control