modelRelativeVelocity
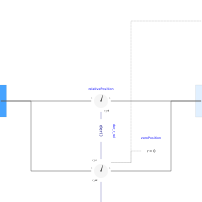
Extends from Internal.PartialRelativeSensor (Partial relative sensor model for sensors defined by components).
Information
The relative velocity vector between the origins of frame_a
and of frame_b are determined and provided at the output signal
connector v_rel.
Via parameter resolveInFrame it is defined, in which frame
the velocity vector is resolved.
| resolveInFrame = … | Output vector resolved in |
|---|---|
| Types.ResolveInFrameAB.world | world frame |
| Types.ResolveInFrameAB.frame_a | frame_a |
| Types.ResolveInFrameAB.frame_b | frame_b |
| Types.ResolveInFrameAB.frame_resolve | frame_resolve (must be connected) |
If resolveInFrame = Types.ResolveInFrameAB.frame_resolve,
the conditional connector frame_resolve is enabled
and v_rel is resolved in the frame, to which
frame_resolve is connected.
Note, if this connector is enabled, it must be connected.
Example: If resolveInFrame = Types.ResolveInFrameAB.frame_resolve, the output vector is computed as:


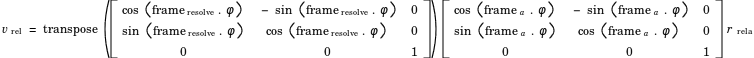
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.MultiBody.Types.ResolveInFrameAB | resolveInFrame | Modelica.Mechanics.MultiBody.Types.ResolveInFrameAB.frame_a | Frame in which output vector v_rel shall be resolved (1: world, 2: frame_a, 3: frame_b, 4: frame_resolve) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Interfaces.Frame_a | frame_a (from PartialRelativeSensor) | Coordinate system a | |
| Interfaces.Frame_b | frame_b (from PartialRelativeSensor) | Coordinate system b | |
| Modelica.Blocks.Interfaces.RealOutput[3] | v_rel | Vector of relative measurements from frame_a to frame_b on velocity level, resolved in frame defined by resolveInFrame | |
| Interfaces.Frame_resolve | frame_resolve | Coordinate system in which v_rel is optionally resolved |
Revisions
 Developed 2010 at the DLR Institute of System Dynamics and Control