modelQuadraticSpeedDependentForce
External force and torque acting at frame_b, defined by 3 input signals and resolved in world frame
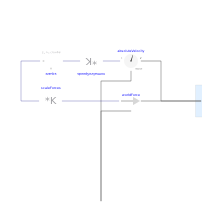
Information
A force applied on frame_b which is quadratic dependent on
the velocity of this frame. Both the measured velocity and the applied force
are resolved in the same frame which is defined via parameter
resolveInFrame as follows:
| Types.ResolveInFrameA. | Meaning |
|---|---|
| world | Resolve input force in world frame (= default) |
| frame_a | Resolve input force in frame_b |
| frame_resolve | Resolve input force in frame_resolve (frame_resolve must be connected) |
This model is e.g. suitable to simulate aerodynamic drag forces.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.MultiBody.Types.ResolveInFrameA | resolveInFrame | Modelica.Mechanics.MultiBody.Types.ResolveInFrameA.world | Frame in which output vector r_rel shall be resolved (1: world, 2: frame_a, 3: frame_resolve) |
| SI.Force | F_nominal | Nominal force (if negative, torque is acting as load) | |
| SI.Velocity | v_nominal | Nominal speed | |
| SI.Torque | tau_nominal | Nominal torque (if negative, torque is acting as load) | |
| SI.AngularVelocity | w_nominal | Nominal speed | |
| Boolean | animation | true | = true, if animation shall be enabled |
| Animation › If animation = true | |||
| Real | N_to_m | planarWorld.defaultN_to_m | Force arrow scaling (length = force/N_to_m) |
| Real | Nm_to_m | planarWorld.defaultNm_to_m | Torque arrow scaling (length = torque/Nm_to_m) |
| SI.Length | zPosition | planarWorld.defaultZPosition | Position z of cylinder representing the fixed translation |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Interfaces.Frame_b | frame_b | Coordinate system fixed to the component with one cut-force and cut-torque | |
| Interfaces.Frame_resolve | frame_resolve | Coordinate system in which vector is optionally resolved, if useExtraFrame is true |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| PlanarWorld | planarWorld | Planar world model | |
| SI.Diameter | diameter | planarWorld.defaultArrowDiameter | Has no longer an effect and is only kept for backwards compatibility (arrow visualization by Vector now) |
| MB.Types.Color | color | PlanarMechanics.Types.Defaults.ForceColor | Color of arrow |
| MB.Types.SpecularCoefficient | specularCoefficient | planarWorld.defaultSpecularCoefficient | Reflection of ambient light (= 0: light is completely absorbed) |
| SI.Force[3] | force | worldForce.force | |
| Sensors.AbsoluteVelocity | absoluteVelocity | ||
| WorldForce | worldForce | ||
| Modelica.Blocks.Math.MatrixGain | normalizeSpeeds | ||
| Modelica.Blocks.Math.MatrixGain | scaleForces | ||
| Utilities.Blocks.SquaretimesSign | square |
Revisions
 Developed 2010 at the DLR Institute of System Dynamics and Control