modelWorldForce
External force and torque acting at frame_b, defined by 3 input signals and resolved in world frame
Information
The 3 signals of the force connector contain force and torque.
The first and second signal are interpreted as the x- and y-coordinates of
a force and the third is torque, acting at the frame connector
to which frame_b of this component is attached.
Note that torque is a scalar quantity, which is exerted perpendicular
to the x-y plane.
An example of this model is given in the following figure:
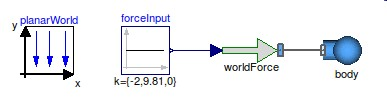
The parameter resolveInFrame defines in which frame the input force shall be resolved.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.MultiBody.Types.ResolveInFrameB | resolveInFrame | Modelica.Mechanics.MultiBody.Types.ResolveInFrameB.frame_b | Frame in which output vector r_rel shall be resolved (1: world, 2: frame_b, 3: frame_resolve) |
| Boolean | animation | true | = true, if animation shall be enabled |
| Animation › If animation = true | |||
| Real | N_to_m | planarWorld.defaultN_to_m | Force arrow scaling (length = force/N_to_m) |
| Real | Nm_to_m | planarWorld.defaultNm_to_m | Torque arrow scaling (length = torque/Nm_to_m) |
| SI.Length | zPosition | planarWorld.defaultZPosition | Position z of cylinder representing the fixed translation |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Interfaces.Frame_b | frame_b | Coordinate system fixed to the component with one cut-force and cut-torque | |
| Modelica.Blocks.Interfaces.RealInput[3] | force | x-, y-coordinates of force and torque resolved in world frame | |
| Interfaces.Frame_resolve | frame_resolve | Coordinate system in which vector is optionally resolved, if useExtraFrame is true |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| PlanarWorld | planarWorld | Planar world model | |
| SI.Diameter | diameter | planarWorld.defaultArrowDiameter | Has no longer an effect and is only kept for backwards compatibility (arrow visualization by Vector now) |
| MB.Types.Color | color | PlanarMechanics.Types.Defaults.ForceColor | Color of arrow |
| MB.Types.SpecularCoefficient | specularCoefficient | planarWorld.defaultSpecularCoefficient | Reflection of ambient light (= 0: light is completely absorbed) |
| Real[2,2] | R | Rotation matrix from world frame to frame_b | |
| SI.Angle | phi | Rotation angle of the additional frame_c |
Revisions
 Developed 2010 at the DLR Institute of System Dynamics and Control