modelRotor
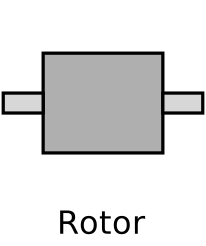
Rigid rotating mass
Extends from Partials.RigidRotorBase (Rigid rotor base).
Information
Rotating rigid mass with two flanges.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Inertia | J (from RigidRotorBase) | 1 | inertia |
| Initialization | |||
| Types.Dynamics | dynType (from RigidRotorBase) | system.dynType | transient or steady-state model |
| SI.AngularVelocity | w_start (from RigidRotorBase) | 0 | start value of angular velocity |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Interfaces.Rotation_p | flange_a (from Flange_a_b) | flange side a | |
| Interfaces.Rotation_n | flange_b (from Flange_a_b) | flange side b |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Angle | phi (from RigidRotorBase) | rotation angle absolute | |
| SI.AngularVelocity | w (from RigidRotorBase) | ||
| SI.AngularAcceleration | a (from RigidRotorBase) |