modelDCMotorCtrl_V4
DC-Motor model based on data from Faulhaber 1724 006 SR
Information
Version 1.3
Created: 14.12.2010
Last modified: 11.07.2011
Model of a Faulhaber 1724 006 SR motor. The parameters shown below are taken from data sheet of the motor. Some properties of the model are as follows:
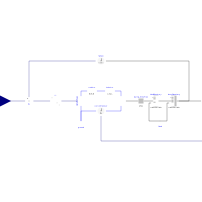
- The motor is attached to an inertia model with frictional torque which is modelled using finite state chart concept.
- The motor is attached to a lossy gear with adjustable gear ratio and also efficiency. By default it has a ratio of 14.4 and an efficiency of 78%
- An ideal gear is attached to the lossy gear to correct the direction of movement of the
A PI controller with anti-windup measure is used to control the speed of the motor.
Clamping of integrator is applied when limit of 6V is exceeded.
V1.3
- viscous friction added to friction model of inertia
| Nominal voltage |
6 | V |
| Terminal resistance |
3.41 | Ohm |
| Output power |
2.58 | W |
| Efficiency |
81 | % |
| No-load speed |
8600 | rpm |
| No-load current (with shaft ? 1,5 mm) |
0.02 | A |
| Stall torque |
11.5 | mNm |
| Friction torque |
0.13 | mNm |
| Speed constant |
1450 | rpm/V |
| Back-EMF constant |
0.690 | mV/rpm |
| Torque constant |
6.59 | mNm/A |
| Current constant |
0.152 | A/mNm |
Parameters
| Type | Name | Default | Description |
|---|
| Real | k | 0.1 | proportional gain |
| Real | Ti | 1/10 | time constant of integral |
| Real | Td | 0 | time constant of derivative |
| Real | Nd | 1000 | High value represents a more ideal derivative block. Reciprocal is equivalent time constant of a PT1 |
| Real | ystart | 0 | integrator start value |
| Real | outMax | 6 | voltage limit in V |
| Real | f_exp | 0.05 | Exponential decay |
| Real | R_w | 1e-4 | viscous friction coeeficient in N.m.rad/s |
| SI.ElectricalTorqueConstant | k_emf | 6.59e-3 | torque constant |
| SI.Resistance | R_res | 3.41 | terminal resistance |
| SI.Inductance | I_ind | 75e-6 | Rotor inductance |
| SI.Torque | M_cou | 3e-4 | 1.3e-4 Coulomb friction |
| SI.Torque | M_str | 6e-4 | 7e-5 Stribeck friction |
| SI.Inertia | J_rot | 1.14e-7 | inertia of rotor 1 gcm2, inertia of code disc 0.09 gcm2, inertia of gear=0.05 gcm2 (estimated based on Maxon gearhead) |