modelRobot_V3
V3
Information
Version 3.1
Created 14.12.2010
Last modified 11.04.2011
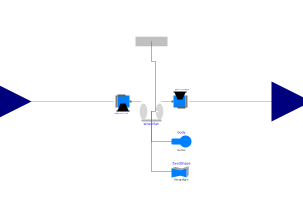
Model of robot with two wheels, actuated independantly by two DC motors.
The model is made up of following parts:
- DC Motor based on Faulhaber 1724 motor with a gear having a ratio of 14.4
- Motor is attached to an inertia block which includes a friction model
- Frictional torque is made up of Coulomb and stribeck friction, viscous friction is neglected
- PI-Controller with limiter
Version History
3.1 - added body to a wheel set, set inertia values based on CAD model of the chassis
Parameters
| Type | Name | Default | Description |
|---|
| Modelica.SIunits.Radius | r_wheel | 0.0155 | radius of wheel |
| Modelica.SIunits.Mass | m_wheel | 0.02 | mass of one wheel |
| Modelica.SIunits.Inertia | I_axis_wheel | 2.6e-6 | inertia along axis of wheel |
| Modelica.SIunits.Inertia | I_long_wheel | 8e-7 | inertia along longitudinal direction of wheel |
| Modelica.SIunits.Distance | d_wheel | 0.09 | distance between the centre of two wheels |
| Modelica.SIunits.Mass | m_chassis | 0.20 | mass of chassis |
| Modelica.SIunits.Inertia | Ix_chassis | 7.5e-5 | inertia of chassis in x-axis, based on CAD model |
| Modelica.SIunits.Inertia | Iy_chassis | 7.5e-5 | inertia of chassis in y-axis, based on CAD model |
| Modelica.SIunits.Inertia | Iz_chassis | 1e-4 | inertia of chassis in z-axis, the vertical axis |
| Modelica.SIunits.Position | xstart_wmr | 0 | start position of x-coordinate of robot |
| Modelica.SIunits.Position | ystart_wmr | 0 | start position of y-coordinate of robot |