modelRotor
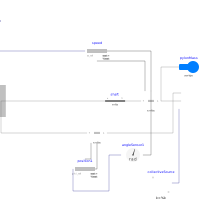
Extends from Modelica.Mechanics.MultiBody.Interfaces.PartialOneFrame_a (Base model for components providing one frame_a connector + outer world + assert to guarantee that the component is connected).
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | rigid | true | |
| Integer | N | 6 | Blade discretization |
| Boolean | orientation_ccw | true | Rotor orientation (=true for counter-clockwise) |
| SI.Velocity | v_freestream | 0.0 | Free-stream velocity |
| Real | n_freestream | {1, 0, 0} | Free-stream velocity direction (in world coordinates) |
| Real | shaft_length | 0.08898774 | Length of shaft from gimbal to blades(m) |
| Real | twist75 | 35.0 | Twist at 3/4 span (deg) (for setting collective shift) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Interfaces.Frame_a | frame_a (from PartialOneFrame_a) | Coordinate system fixed to the component with one cut-force and cut-torque | |
| Modelica.Blocks.Interfaces.RealInput | RPM |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Real | AdvRatio | ||
| RotorAeroLib_Globals | RALglb | ||
| Modelica.Mechanics.MultiBody.Joints.Revolute | drive | ||
| RotorBladeAssembly | bladeAssm | ||
| Modelica.Mechanics.MultiBody.Parts.Body | pylonMass | ||
| Modelica.Blocks.Sources.Constant | collectiveSource | ||
| Modelica.Mechanics.MultiBody.Joints.Revolute | driveFollower | ||
| Modelica.Mechanics.Rotational.Sensors.AngleSensor | angleSensor1 | ||
| Modelica.Mechanics.Rotational.Sources.Position | position1 | ||
| Modelica.Mechanics.MultiBody.Parts.FixedTranslation | shaft | ||
| Modelica.Mechanics.Rotational.Sources.Speed | speed |