blockRRInverseKinematics
Generic equation of a 2R mechanism inverse kinematics
Extends from Modelica.Blocks.Interfaces.MIMO (Multiple Input Multiple Output continuous control block).
Information
General
With this block the inverse kinematics of rotational-rotational mechanism given the specifications of RR model is obtain Servomechanisms.Mechanism.RR.
Implementation
It inherits the real interfaces from the block for multiple inputs and multiple outputs Modelica.Blocks.Interfaces.MIMO
The joint variables are determine by:
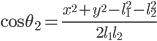
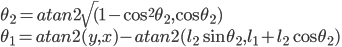
Notes
- The input is an array u where u[1] is the x coordinate and u[2] is the y coordinate of a trayectory located at final frame of the second link. To connect a signal to the intput u the user must input the index of the array (1 or 2).
- The output is an array y where y[1] is the first joint coordinate and y[2] is the second joint coordinate. To connect the output y to other component the user must input the index of the array (1 or 2).
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Integer | nin (from MIMO) | 1 | Number of inputs |
| Integer | nout (from MIMO) | 1 | Number of outputs |
| Real | l1 | 1 | length of link 1 |
| Real | l2 | 1 | length of link 2 |
| Real | elbow | 1 | elbow direction: -1 (elbow up), 1 (elbow down) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| RealInput[nin] | u (from MIMO) | Connector of Real input signals | |
| RealOutput[nout] | y (from MIMO) | Connector of Real output signals |