recordSynchron_el
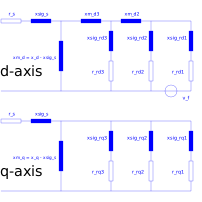
Extends from Synchron3rd_el (Synchronous machine 3rd order parameters).
Information
Equivalent circuit on diagram layer!
Specifying standard transient data both for _d and _q axis:
- for first order write
  xtr = {0.4}   for  xtr'  = 0.4,  no xtr''
  tc  = {1.3}   for   tc'  = 1.3,   no tc''
  and
  xtr = {0.26}  for  xtr'' = 0.26,  no xtr'
  tc  = {0.06}  for   tc'' = 0.06,   no tc'
- for second order write
  xtr = {0.4, 0.24}  for  xtr' = 0.4, xtr'' = 0.24
  tc  = {1.3, 0.04}  for   tc' = 1.3,  tc'' = 0.04
and analogous for higher order.
Sign of field current i_f:
Mathematical conventions (Z-matrix) are used for formulas in package 'Precalculation'.
Experimental conventions (if0_deg) choose the inverse sign for the field-current.
Therefore we have to use the following definition for the phase-angle of i_f:
alpha_if0 = (if0_deg + 180)*pi/180
If the induced field-current values are not available and for pm-excitation the d-axis is treated according to the q-axis scheme (without xm_d).
Specifying equivalent circuit data:
xsig_f, r_f, xsig_Q, r_Q correspond to a stator-based equivalent circuit.
The number of components of xsig_r, r_r depends on the order of the model.
For pu-input refer to stator base value R_base.
Relation rotor resistance of field winding to stator-based equivalent circuit data:
  If_base = (x_d - xsig_s)*If_nom, (x_d, xsig_s in pu)
  Rf_base = P_nom/If_base^2
  rf =  Rf/Rf_base                (in pu, stator-based).
  rf = (Rf/Rf_base)*R_base        (in SI, stator-based).
  Rf = resistance field winding   (in Ohm, true value, not scaled)
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | neu_iso (from Synchron3rd_el) | false | isolated neutral if Y |
| Integer | pp (from Synchron3rd_el) | 1 | pole-pair number |
| Integer | excite (from Synchron3rd_el) | 1 | excitation (1:el) |
| SIpu.MagneticFlux | psi_pm (from Synchron3rd_el) | 0 | magnetisation (V/V_nom at open term at omega_nom) |
| SIpu.Reactance | x_d (from Synchron3rd_el) | 1.9 | syn reactance d-axis |
| SIpu.Reactance | x_q (from Synchron3rd_el) | 1.77 | syn reactance q-axis |
| SIpu.Reactance | x_o (from Synchron3rd_el) | 0.1 | reactance o-axis |
| SIpu.Resistance | r_s (from Synchron3rd_el) | 0.005 | resistance armature |
| SIpu.Resistance | r_n (from Synchron3rd_el) | 1 | resistance neutral to grd (if Y) |
| Boolean | transDat | true | use transient data? |
| Boolean | use_xtr | true | use x_transient and t_closed? |
| SIpu.Reactance | xtr_d | {0.33, 0.25} | trans reactance d-axis {xtr_d', xtr_d'', ..} |
| SIpu.Reactance | xtr_q | {0.44, 0.27} | trans reactance q-axis {xtr_q', xtr_q'', ..} |
| SI.Time | tc_d | {0.86, 0.025} | time constant closed-loop d-axis {tc_d', tc_d'', ..} |
| SI.Time | tc_q | {0.25, 0.04} | time constant closed-loop q-axis {tc_q', tc_q'', ..} |
| SI.Time | to_d | {4.9898, 0.032747} | time constant open-loop d-axis {to_d', to_d'', ..} |
| SI.Time | to_q | {1.0867, 0.060327} | time constant open-loop q-axis {to_q', to_q'', ..} |
| Boolean | use_if0 | true | induced field current and phase available? |
| SIpu.Current | if0 | 0.85 | induced field current at v_s=Vnom/0deg |
| SIpu.Angle_deg | if0_deg | -100 | angle(if0) at v_s=Vnom/0deg (sign: i_f behind v_s) |
| Real | tol | 1e-6 | tolerance precalculation |
| SIpu.Reactance | xsig_s | 0.17 | leakage reactance armature |
| SIpu.Reactance | xsig_rd | {0.135194, 0.0365214} | leakage reactance rotor d-axis {f, D, ..} |
| SIpu.Reactance | xsig_rq | {0.407386, 0.144502} | leakage reactance rotor q-axis {Q1, ..} |
| SIpu.Reactance | xm_d | {0.0555125} | coupling-reactance d-axis {xm1, ..} |
| SIpu.Resistance | r_rd | {1.32139e-3, 14.376e-3} | resistance rotor d-axis {f, D, ..} |
| SIpu.Resistance | r_rq | {7.38411e-3, 19.7148e-3} | resistance rotor q-axis {Q1, ..} |
| Nominal | |||
| Base.Types.Units | units (from Nominal) | Types.pu | SI | pu |
| SI.Voltage | V_nom (from Nominal) | 1 | nom Voltage (= base if pu) |
| SI.ApparentPower | S_nom (from Nominal) | 1 | nom Power (= base if pu) |
| SI.Frequency | f_nom (from NominalDataAC) | 50 | nom frequency |
| SI.Current | If_nom | 1 | nom field current (V=V_nom at open term) |