modelTractionWheel
Traction wheel
Information
The model relates traction force and torque on wheel, using a rail-wheel friction model.
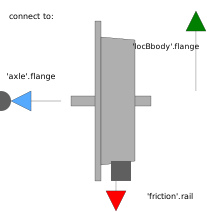
Connectors have to be connected as indicated below.
The connector variable rail.s fulfills
der(rail.s) = v_slip = v_rotation - v_translationwith
  v_rotation = r*der(phi),  phi   rotation angle of wheel
  v_translation = der(s),   s     position of wheel
This choice avoids the introduction of a special connector with a velocity variable.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Inertia | J | 1 | inertia wheel |
| SI.Radius | r | 1 | radius wheel |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Base.Interfaces.Rotation_p | wheel | to torque source, (driving axle) | |
| Base.Interfaces.Translation_n | frame | to loc-body (delivers tractive force) | |
| Base.Interfaces.Translation_p | rail | to rail-wheel friction model |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Angle | phi | rotation angle wheel | |
| SI.AngularVelocity | w | ||
| SI.AngularAcceleration | a |