modelFunctions_jointsCoordinates_actuatorsJointsRotationAngles_test
Test of functions 'jointsCoordinates' and 'actuatorsJointsRotationAngles'
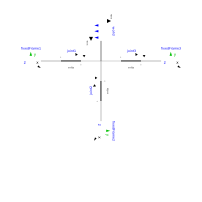
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| DeltaRobot.Types.DiscParameters | discParameters | Parameters of the base/platform | |
| Modelica.Mechanics.MultiBody.Types.RotationSequence | rotationSequence | {3, 1, 3} | Sequence of rotations relative to function 'actuatorsJointsRotationAngles' |
| SI.Position[3,3] | J | jointsCoordinates(discParameters) | Coordinates of the joints resolved in base/platform frame |
| NonSI.Angle_deg[3,3] | alpha | actuatorsJointsRotationAngles(discParameters) | Rotation angles to rotate base/platform frame into the frames of base/platform joints |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.MultiBody.World | world | ||
| Modelica.Mechanics.MultiBody.Parts.FixedRotation | joint1 | ||
| Modelica.Mechanics.MultiBody.Parts.FixedRotation | joint2 | ||
| Modelica.Mechanics.MultiBody.Parts.FixedRotation | joint3 | ||
| Modelica.Mechanics.MultiBody.Visualizers.FixedFrame | fixedFrame1 | ||
| Modelica.Mechanics.MultiBody.Visualizers.FixedFrame | fixedFrame2 | ||
| Modelica.Mechanics.MultiBody.Visualizers.FixedFrame | fixedFrame3 |