blockPositionController
Position controller
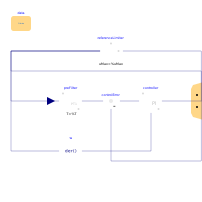
Extends from DriveControl.Interfaces.PartialController (Partial controller block).
Information
Position controller as explained in the User's guide, Position controller.
Necessary signals are read from and written to the signal bus.
Parameters are calculated in the data record.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| DataRecords.Data | data (from PartialController) | ||
| Advanced | |||
| Real | kTune (from PartialController) | 1 | Tune proportional gain of controller |
| Boolean | use_preFilter (from PartialController) | true | Use reference pre-filter? |
| Real | kFF_Speed | 0 | Feed-forward of speed |
| Modelica.Units.SI.Angle | phi0 | 0 | Initial position |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Interfaces.DriveBus | driveBus (from PartialController) |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Nonlinear.Limiter | referenceLimiter (from PartialController) | ||
| Modelica.Blocks.Continuous.FirstOrder | preFilter (from PartialController) | ||
| Modelica.Blocks.Math.Feedback | controlError (from PartialController) | ||
| Blocks.LimPI | controller (from PartialController) | ||
| Modelica.Blocks.Continuous.Der | w |