packageContinuous
Continuous control blocks
Extends from Icons.Package (Icon for standard packages).
Contents
| Name | Description |
|---|---|
| BaseClasses | Base continuous control blocks |
 AbsLimRateLimFeedthroughFreeze | First order feed-through with absolute and rate limits, and a freezing flag, used when first order filter is bypassed |
 AbsLimRateLimFeedthroughFreezeLimDetection | First order feed-through with absolute and rate limits, a freezing flag, and limitation detection flags |
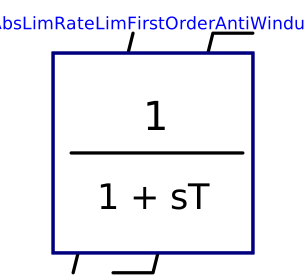 AbsLimRateLimFirstOrderAntiWindup | First order filter with absolute and rate limits, and an anti-windup loop |
 AbsLimRateLimFirstOrderFreeze | First order filter with absolute and rate limits, and a freezing flag |
 AbsLimRateLimFirstOrderFreezeLimDetection | First order filter with absolute and rate limits, a freezing flag, and limitation detection flags |
 AntiWindupIntegrator | Integrator with absolute and rate limits, anti windup and anti winddown |
 DecreaseDetection | Output y is true, if the input u has fallen to a lower value since the previous sample |
 DiscreteIntegrator | Integrator with discrete input |
 IncreaseDetection | Output y is true, if the input u has risen to a higher value since the previous sample |
 IntegratorWithReset | Integrator with absolute limits and reset |
 IntegratorSetFreeze | Outputs the integral of the input signal with optional set/reset and optional state freeze |
 IntegratorVariableLimits | Integrator with limited value of output (variable limits) and freeze |
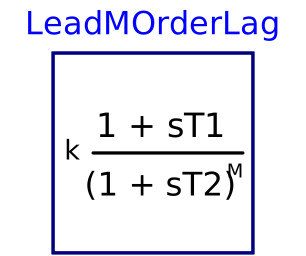 LeadMOrderLag | Lead-lag filter with M poles |
 LimitedPI | Proportional-integrator controller with limited value of output |
 LimPIDFreeze | PI controller with limited output, anti-windup compensation, setpoint weighting, optional feed-forward and optional freezing of the state |
 PI | Proportional-integral controller |
 PIAntiWindup | Anti-windup proportional integral controller |
 PIAntiWindupVariableLimits | Anti-windup proportional integral controller with variable limits |
 PIFreeze | Proportional-integrator controller with freezing of the state |
 Power | Outputs a power of the input |
 RampTrackingFilter | Ramp tracking filter |
 RateLimFirstOrderFreeze | First order transfer function block with rate limiter and freeze functionality |
 SecondOrder | Second order filter block, allowing for zero coefficients |
 SqrtNoEvent | If the input is positive, outputs its square root, if the input is negative, outputs zero |
 TransferFunction | Linear transfer function |
 TransferFunctionBypass | Linear transfer function, bypassed if highest-order coefficient of denominator is zero |
 VarLimPIDFreeze | PI controller with limited output (with adjustable limits), anti-windup compensation, setpoint weighting, optional feed-forward and optional freezing of the state |
 Washout | Washout filter block, allowing for zero time constant |
 WeightedDifference | Block which calculates the weighted difference between an input variable and a reference parameter |