modelDynamometer
Chassis dynamometer
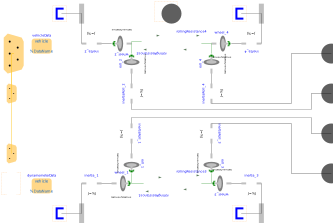
Extends from VehicleInterfaces.Chassis.Interfaces.TwoAxleBase (Interface definition for a chassis of a 4 wheeled vehicle), VehicleInterfaces.Icons.Chassis (Icon for a chassis subsystem), Modelica.Icons.UnderConstruction (Icon for classes that are still under construction).
Information
1-dimensioanl model of a chassis dynaometer, taking into account:
- 4 wheels with radius and inertia
- constant rolling friction
- 4 rolls with radius and inertia
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| EMOTH.ParameterRecords.Vehicles.VehicleData | vehicleData | ||
| EMOTH.ParameterRecords.Dynamometer.DynamometerData | dynamometerData | ||
| Modelica.Units.SI.Force | FRoll | dynamometerData.cr*vehicleData.m*g_n | Constant rolling reistance |
| Advanced › Only for 1D chassis | |||
| Boolean | usingMultiBodyDriveline (from Base) | false | = true, if connecting to a MultiBody driveline |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.MultiBody.Interfaces.Frame_b | chassisFrame (from Base) | Chassis reference frame (optional) | |
| Modelica.Mechanics.Rotational.Interfaces.Flange_a | steeringWheel (from Base) | Steering wheel connection (optional) | |
| VehicleInterfaces.Interfaces.ControlBus | controlBus (from Base) | Control signal bus | |
| Modelica.Mechanics.MultiBody.Interfaces.FlangeWithBearing | wheelHub_1 (from TwoAxleBase) | Front left wheel | |
| Modelica.Mechanics.MultiBody.Interfaces.FlangeWithBearing | wheelHub_2 (from TwoAxleBase) | Front right wheel | |
| Modelica.Mechanics.MultiBody.Interfaces.FlangeWithBearing | wheelHub_3 (from TwoAxleBase) | Rear left wheel | |
| Modelica.Mechanics.MultiBody.Interfaces.FlangeWithBearing | wheelHub_4 (from TwoAxleBase) | Rear right wheel | |
| Modelica.Mechanics.Rotational.Interfaces.Flange_a | shaft1 | ||
| Modelica.Mechanics.Rotational.Interfaces.Flange_a | shaft2 | ||
| Modelica.Mechanics.Rotational.Interfaces.Flange_a | shaft3 | ||
| Modelica.Mechanics.Rotational.Interfaces.Flange_a | shaft4 |