modelVehicleWithDrive
Vehicle with friction
Extends from ElectroMechanicalDrives.Components.Vehicles.Vehicle (Vehicle with friction).
Information
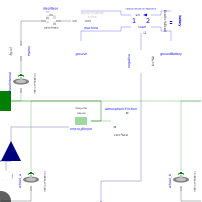
This vehicle model considers
- Rolling friction
- Athmospheric friction
- The effect of effective mass increase due to inertias
- The impact of going up or down an inclined way by means of the constant angle parameter
constantAngeor the signal inputvariableAngle. - The vehicle has to translational sides and two roational axes to be driven
- Ideal gear
- Ideal DC machine considering field weakening range
- Ideal DC/DC converter
- Re-chargeable ideal battery
Note
Do not change v_linear except this is required for numerical reasons
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | useConstantAngle (from ConditionalAngle) | true | If false, signal input is used |
| Modelica.Units.SI.Angle | constantAngle (from ConditionalAngle) | 0 | Constant angle of gradient |
| Modelica.Units.SI.Inertia | J (from Vehicle) | j*m*r^2 | Total inertia with respect to wheel |
| ElectroMechanical › Power train | |||
| Real | i | 1 | Transmission speed ratio machine/wheel |
| ElectroMechanical › Electric machine | |||
| Modelica.Units.SI.ElectricalTorqueConstant | kBase | 1 | Transformation coefficient of base velocity range |
| Modelica.Units.SI.AngularVelocity | wBase | Maximum base angular velocity | |
| ElectroMechanical › Battery | |||
| Integer | ns | 1 | Number of series cells |
| Integer | np | 1 | Number of parallel cells |
| Modelica.Units.SI.Voltage | V1Cell | 4.2 | Maximum cell voltage > V0Cell |
| Modelica.Units.SI.Voltage | V0Cell | 2.5 | Minimum cell voltage < V1Cell |
| Boolean | allowOvercharge | false | Allows overcharging without error |
| Boolean | allowUndercharge | false | Allows undercharging without error |
| Modelica.Units.SI.Energy | ECell | Total cell energy between V0 and V1 | |
| Modelica.Units.SI.Voltage | ViniCell | V1Cell | Initial cell voltage |
| Ambient | |||
| Modelica.Units.SI.Density | rho (from Vehicle) | 1.2 | Mass density of air |
| Real | mu (from Vehicle) | 0.02 | Rolling friction coefficient |
| Vehicle | |||
| Modelica.Units.SI.Area | A (from Vehicle) | 3 | Area of cross section of vehicle |
| Real | cx (from Vehicle) | 0.3 | Drag coefficient (cw in German) |
| Modelica.Units.SI.Mass | m (from Vehicle) | 1000 | Total mass of vehicle |
| Modelica.Units.SI.Length | r (from Vehicle) | 0.35 | Wheel radius |
| Real | j (from Vehicle) | 0 | Relative mass increase due to rotating inertias |
| Tuning | |||
| Modelica.Units.SI.Velocity | v_linear (from Vehicle) | 0.01 | Speed limit of constant rolling friction (do not change unless required) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Interfaces.RealInput | variableAngle (from ConditionalAngle) | Angle of inclination of ramp | |
| Modelica.Mechanics.Translational.Interfaces.Flange_a | flangeT_a (from Vehicle) | Left translational flange of vehicle | |
| Modelica.Mechanics.Translational.Interfaces.Flange_b | flangeT_b (from Vehicle) | Right translational flange of vehicle | |
| Modelica.Mechanics.Rotational.Interfaces.Flange_a | flangeR_a (from Vehicle) | Left rotational flange_a of wheel_a | |
| Modelica.Mechanics.Rotational.Interfaces.Flange_b | flangeR_b (from Vehicle) | Right rotational flange_b of wheel_b | |
| Modelica.Blocks.Interfaces.RealInput | iMachine | Machine current input |