
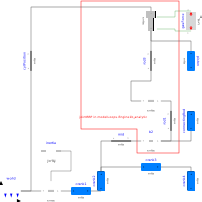
modelEngine1b

Model of one cylinder engine with gas force and preparation for assembly joint JointRRP

Extends from Modelica.Icons.Example (Icon for runnable examples), Utilities.Engine1bBase (Base model for one cylinder engine with gas force).

Information

This is a model of the mechanical part of one cylinder of an engine. It is similar to Loops.Engine1a. The difference is that a simple model for the gas force in the cylinder is added and that the model is restructured in such a way, that the central part of the planar kinematic loop can be easily replaced by the assembly joint "Modelica.Mechanics.MultiBody.Joints.Assemblies.JointRRP". This exchange of the kinematic loop is shown in Loops.Engine1b_analytic. The advantage of using JointRRP is, that the non-linear algebraic equation of this loop is solved analytically, and not numerically as in this model (Engine1b).

An animation of this example is shown in the figure below.
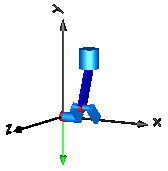
model Examples.Loops.Engine

Components

TypeNameDefaultDescription
Modelica.Mechanics.MultiBody.Worldworld (from Engine1Base)
Modelica.Mechanics.MultiBody.Parts.BodyCylinderpiston (from Engine1Base)
Modelica.Mechanics.MultiBody.Parts.BodyBoxconnectingRod (from Engine1Base)
Modelica.Mechanics.MultiBody.Joints.Revolutebearing (from Engine1Base)
Modelica.Mechanics.Rotational.Components.Inertiainertia (from Engine1Base)
Modelica.Mechanics.MultiBody.Parts.BodyCylindercrank1 (from Engine1Base)
Modelica.Mechanics.MultiBody.Parts.BodyBoxcrank2 (from Engine1Base)
Modelica.Mechanics.MultiBody.Parts.BodyCylindercrank3 (from Engine1Base)
Modelica.Mechanics.MultiBody.Parts.BodyBoxcrank4 (from Engine1Base)
Modelica.Mechanics.MultiBody.Parts.FixedTranslationmid (from Engine1Base)
Modelica.Mechanics.MultiBody.Parts.FixedTranslationcylPosition (from Engine1Base)
GasForce2gasForce (from Engine1bBase)
Modelica.Mechanics.MultiBody.Joints.Revoluteb1
Joints.RevolutePlanarLoopConstraintb2
Modelica.Mechanics.MultiBody.Joints.Prismaticcylinder
Parts.FixedTranslationrod1
Parts.FixedTranslationrod3