
modelEngine1b_analytic

Model of one cylinder engine with gas force and analytic loop handling
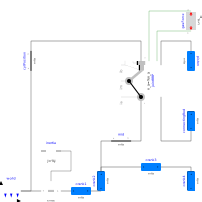
Extends from Modelica.Icons.Example (Icon for runnable examples), Utilities.Engine1bBase (Base model for one cylinder engine with gas force).

Information

This is the same model as Loops.Engine1b. The only difference is that the central part of the planar kinematic loop has been replaced by the assembly joint "Modelica.Mechanics.MultiBody.Joints.Assemblies.JointRRP". The advantage of using JointRRP is, that the non-linear algebraic equation of this loop is solved analytically, and not numerically as in Loops.Engine1b.

An animation of this example is shown in the figure below.
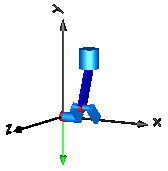
model Examples.Loops.Engine

Components

TypeNameDefaultDescription
Modelica.Mechanics.MultiBody.Worldworld (from Engine1Base)
Modelica.Mechanics.MultiBody.Parts.BodyCylinderpiston (from Engine1Base)
Modelica.Mechanics.MultiBody.Parts.BodyBoxconnectingRod (from Engine1Base)
Modelica.Mechanics.MultiBody.Joints.Revolutebearing (from Engine1Base)
Modelica.Mechanics.Rotational.Components.Inertiainertia (from Engine1Base)
Modelica.Mechanics.MultiBody.Parts.BodyCylindercrank1 (from Engine1Base)
Modelica.Mechanics.MultiBody.Parts.BodyBoxcrank2 (from Engine1Base)
Modelica.Mechanics.MultiBody.Parts.BodyCylindercrank3 (from Engine1Base)
Modelica.Mechanics.MultiBody.Parts.BodyBoxcrank4 (from Engine1Base)
Modelica.Mechanics.MultiBody.Parts.FixedTranslationmid (from Engine1Base)
Modelica.Mechanics.MultiBody.Parts.FixedTranslationcylPosition (from Engine1Base)
GasForce2gasForce (from Engine1bBase)
Joints.Assemblies.JointRRPjointRRP